Two seasons, two robots.
ORION
2026 · REBUILT
District event winner, Fort Worth
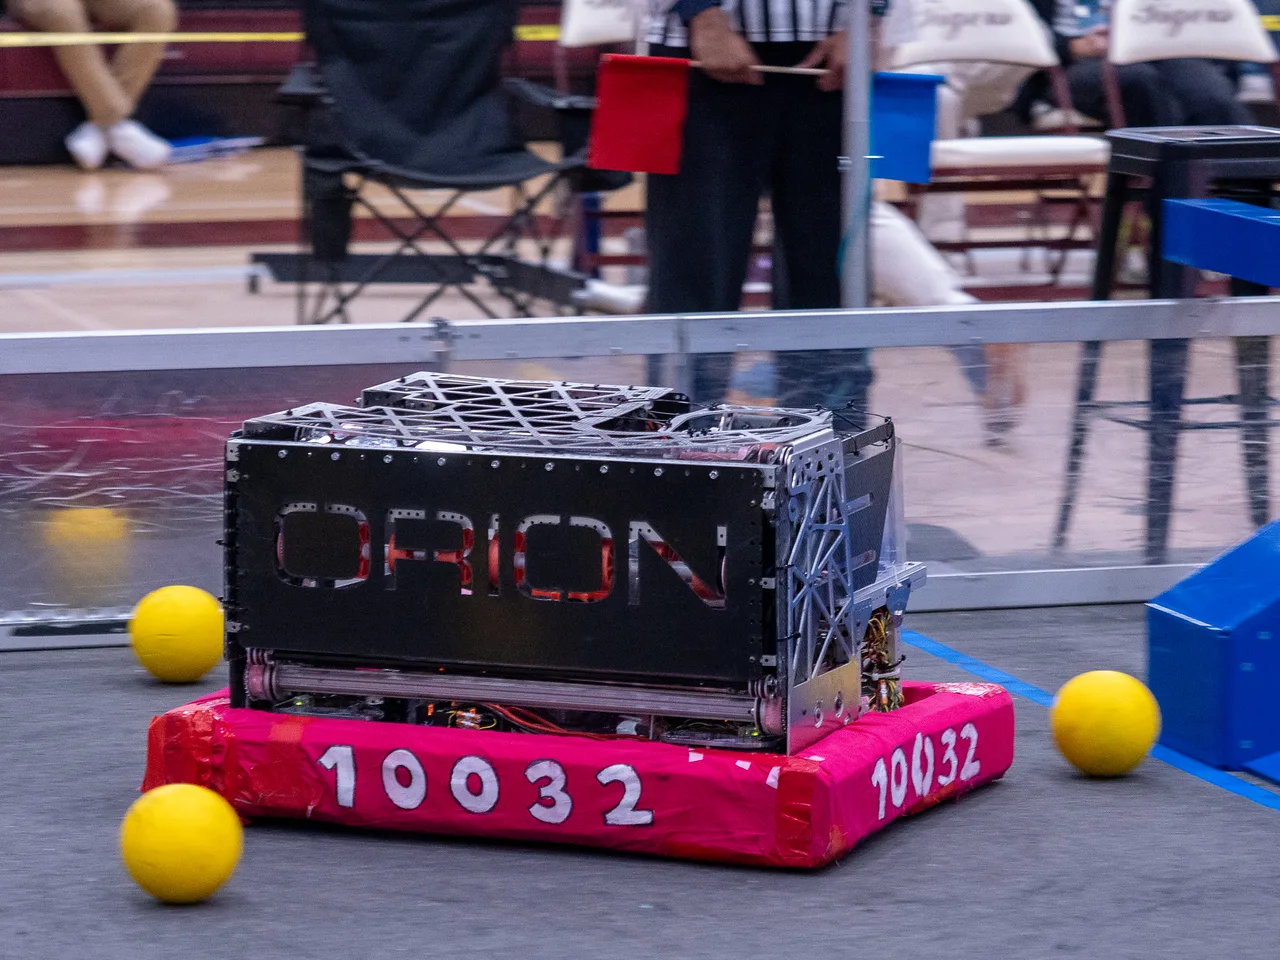
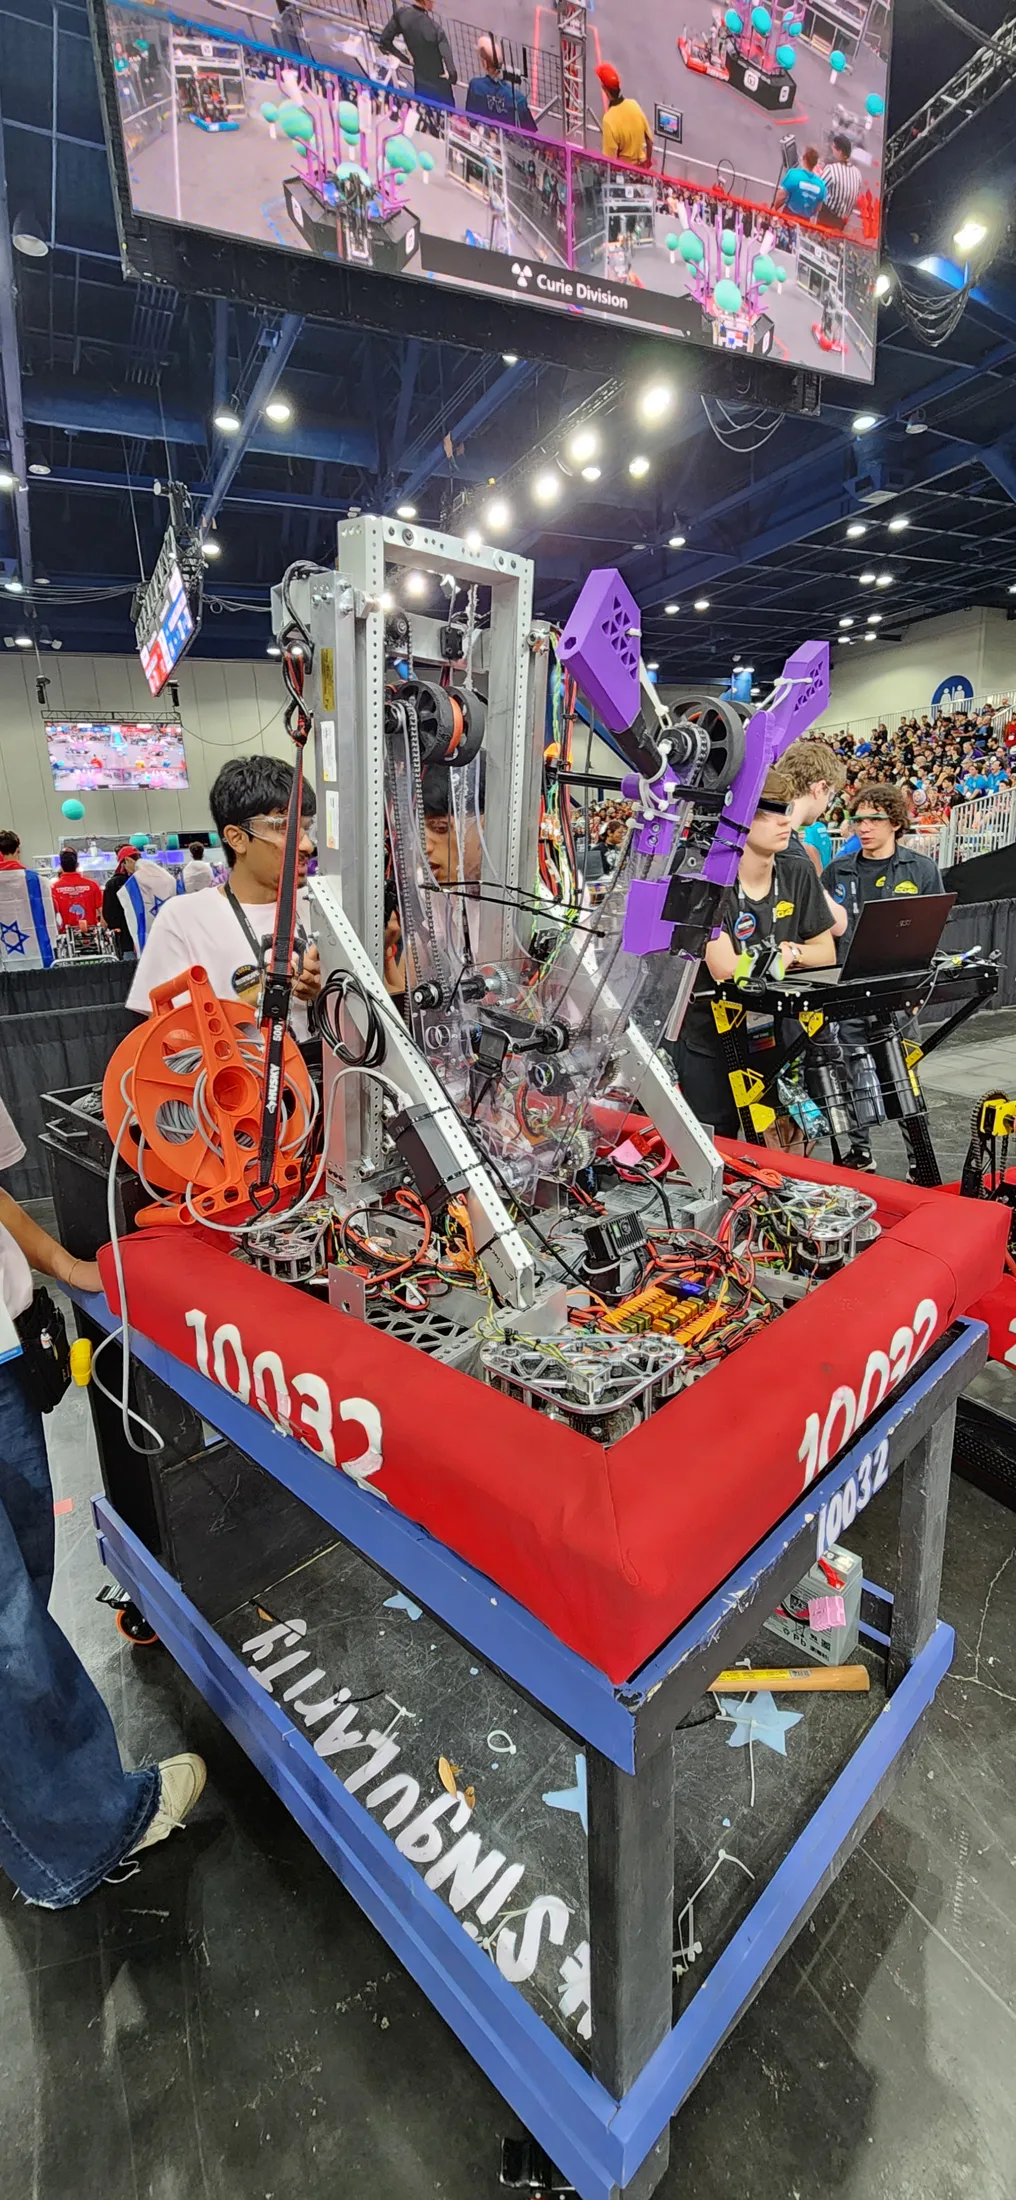
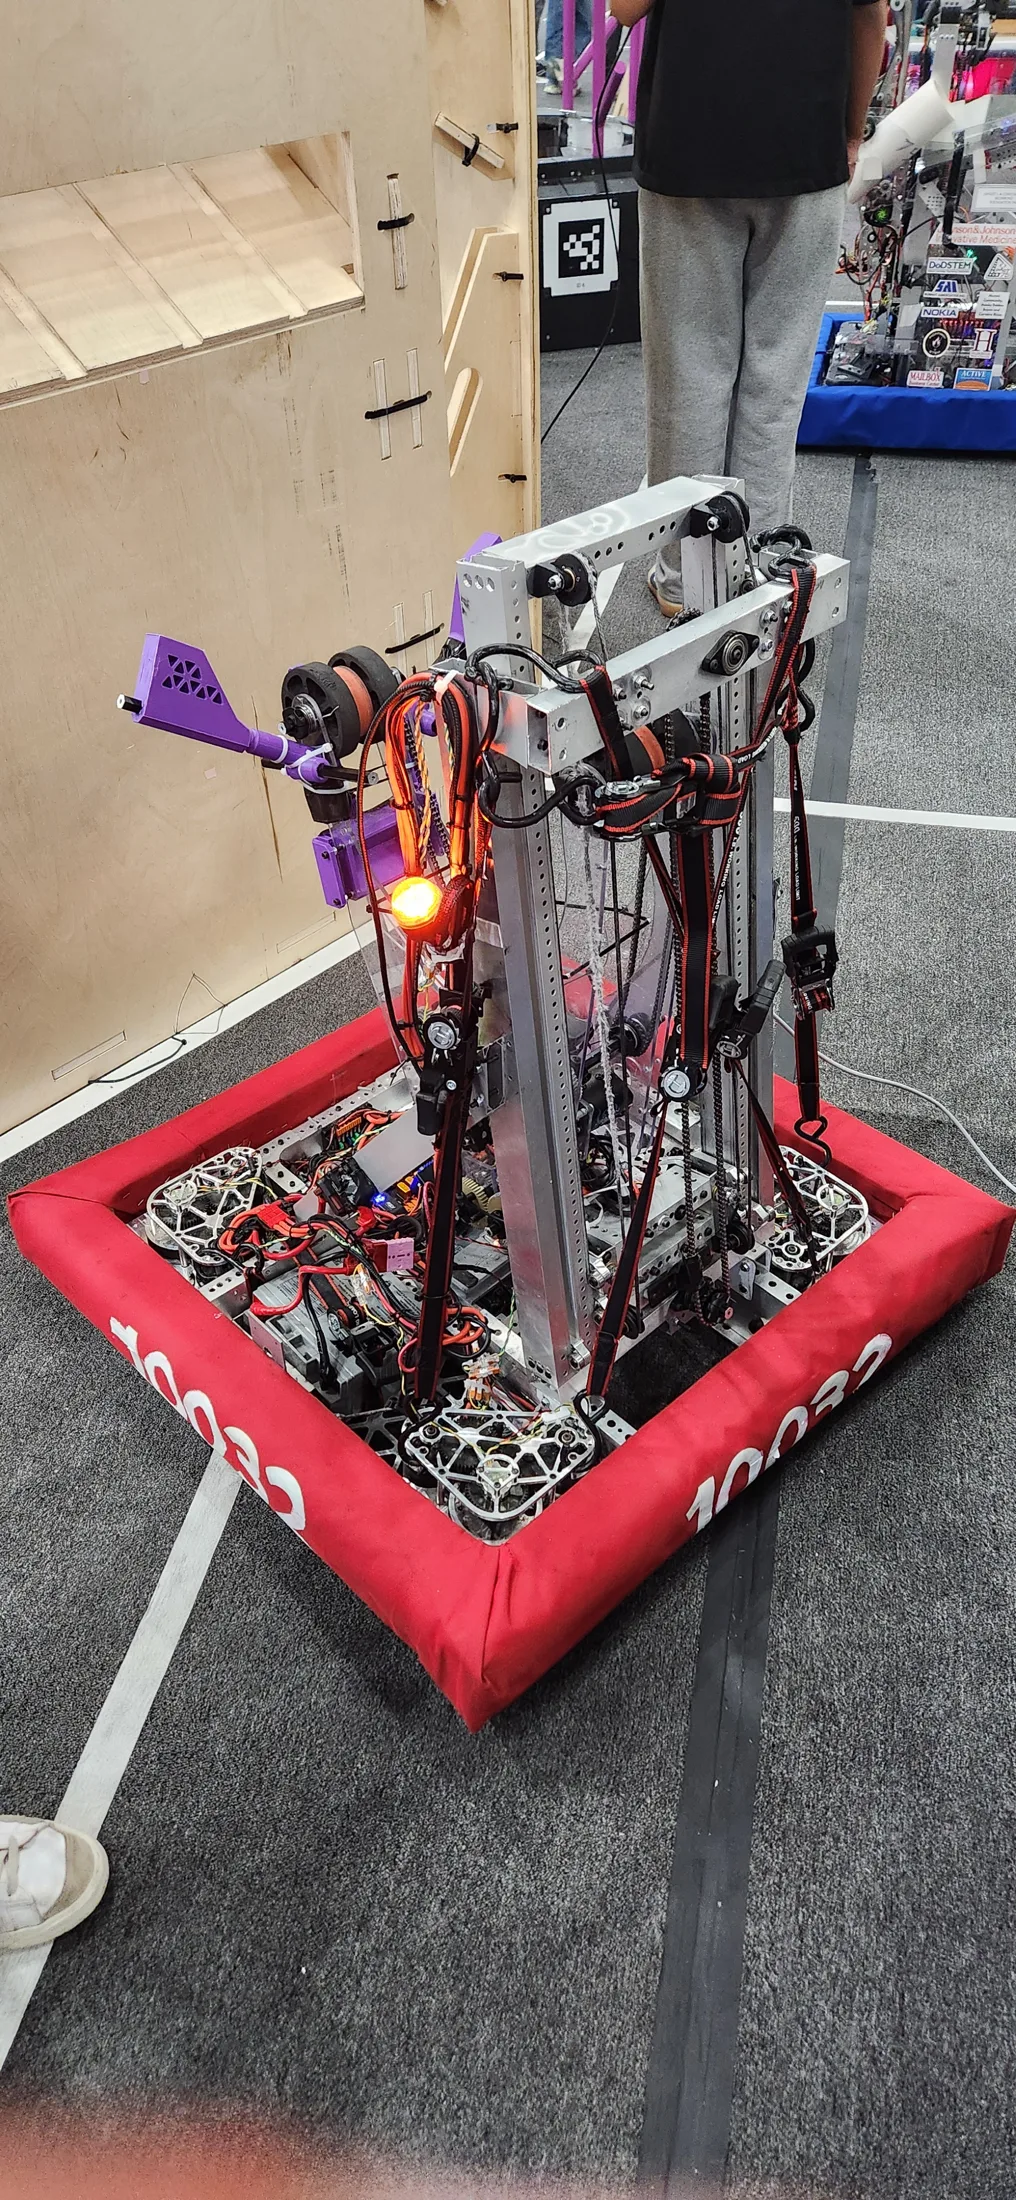
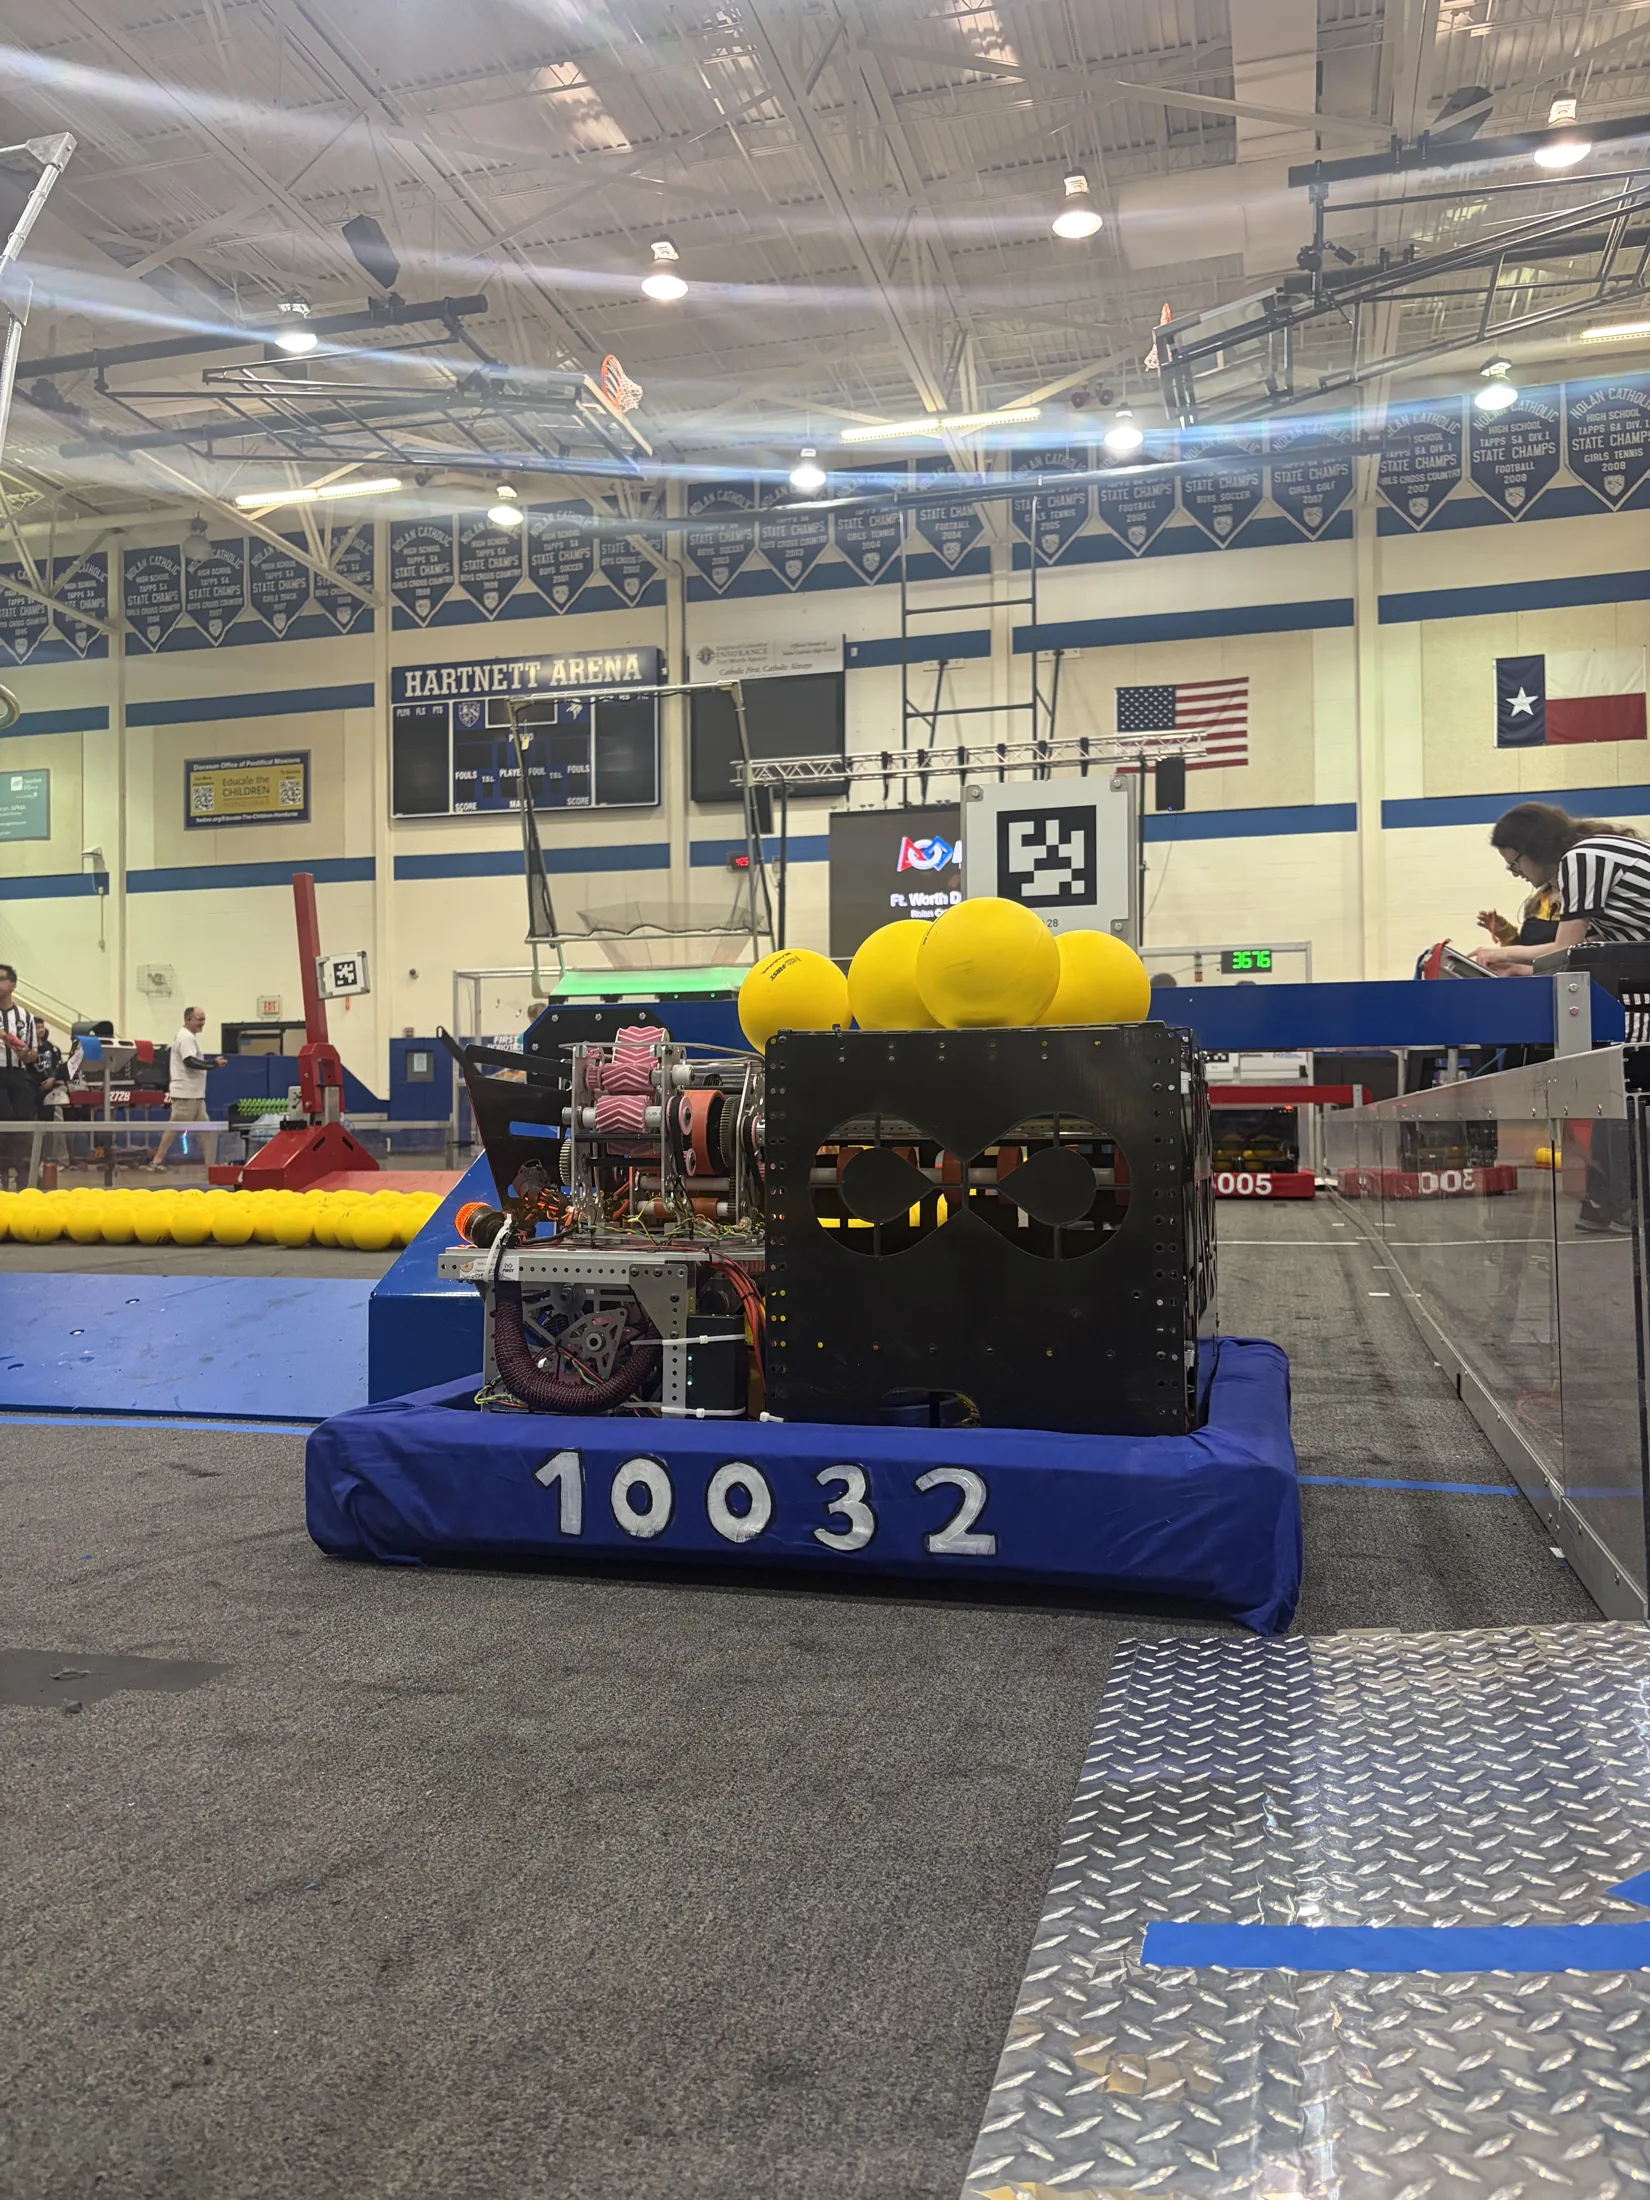
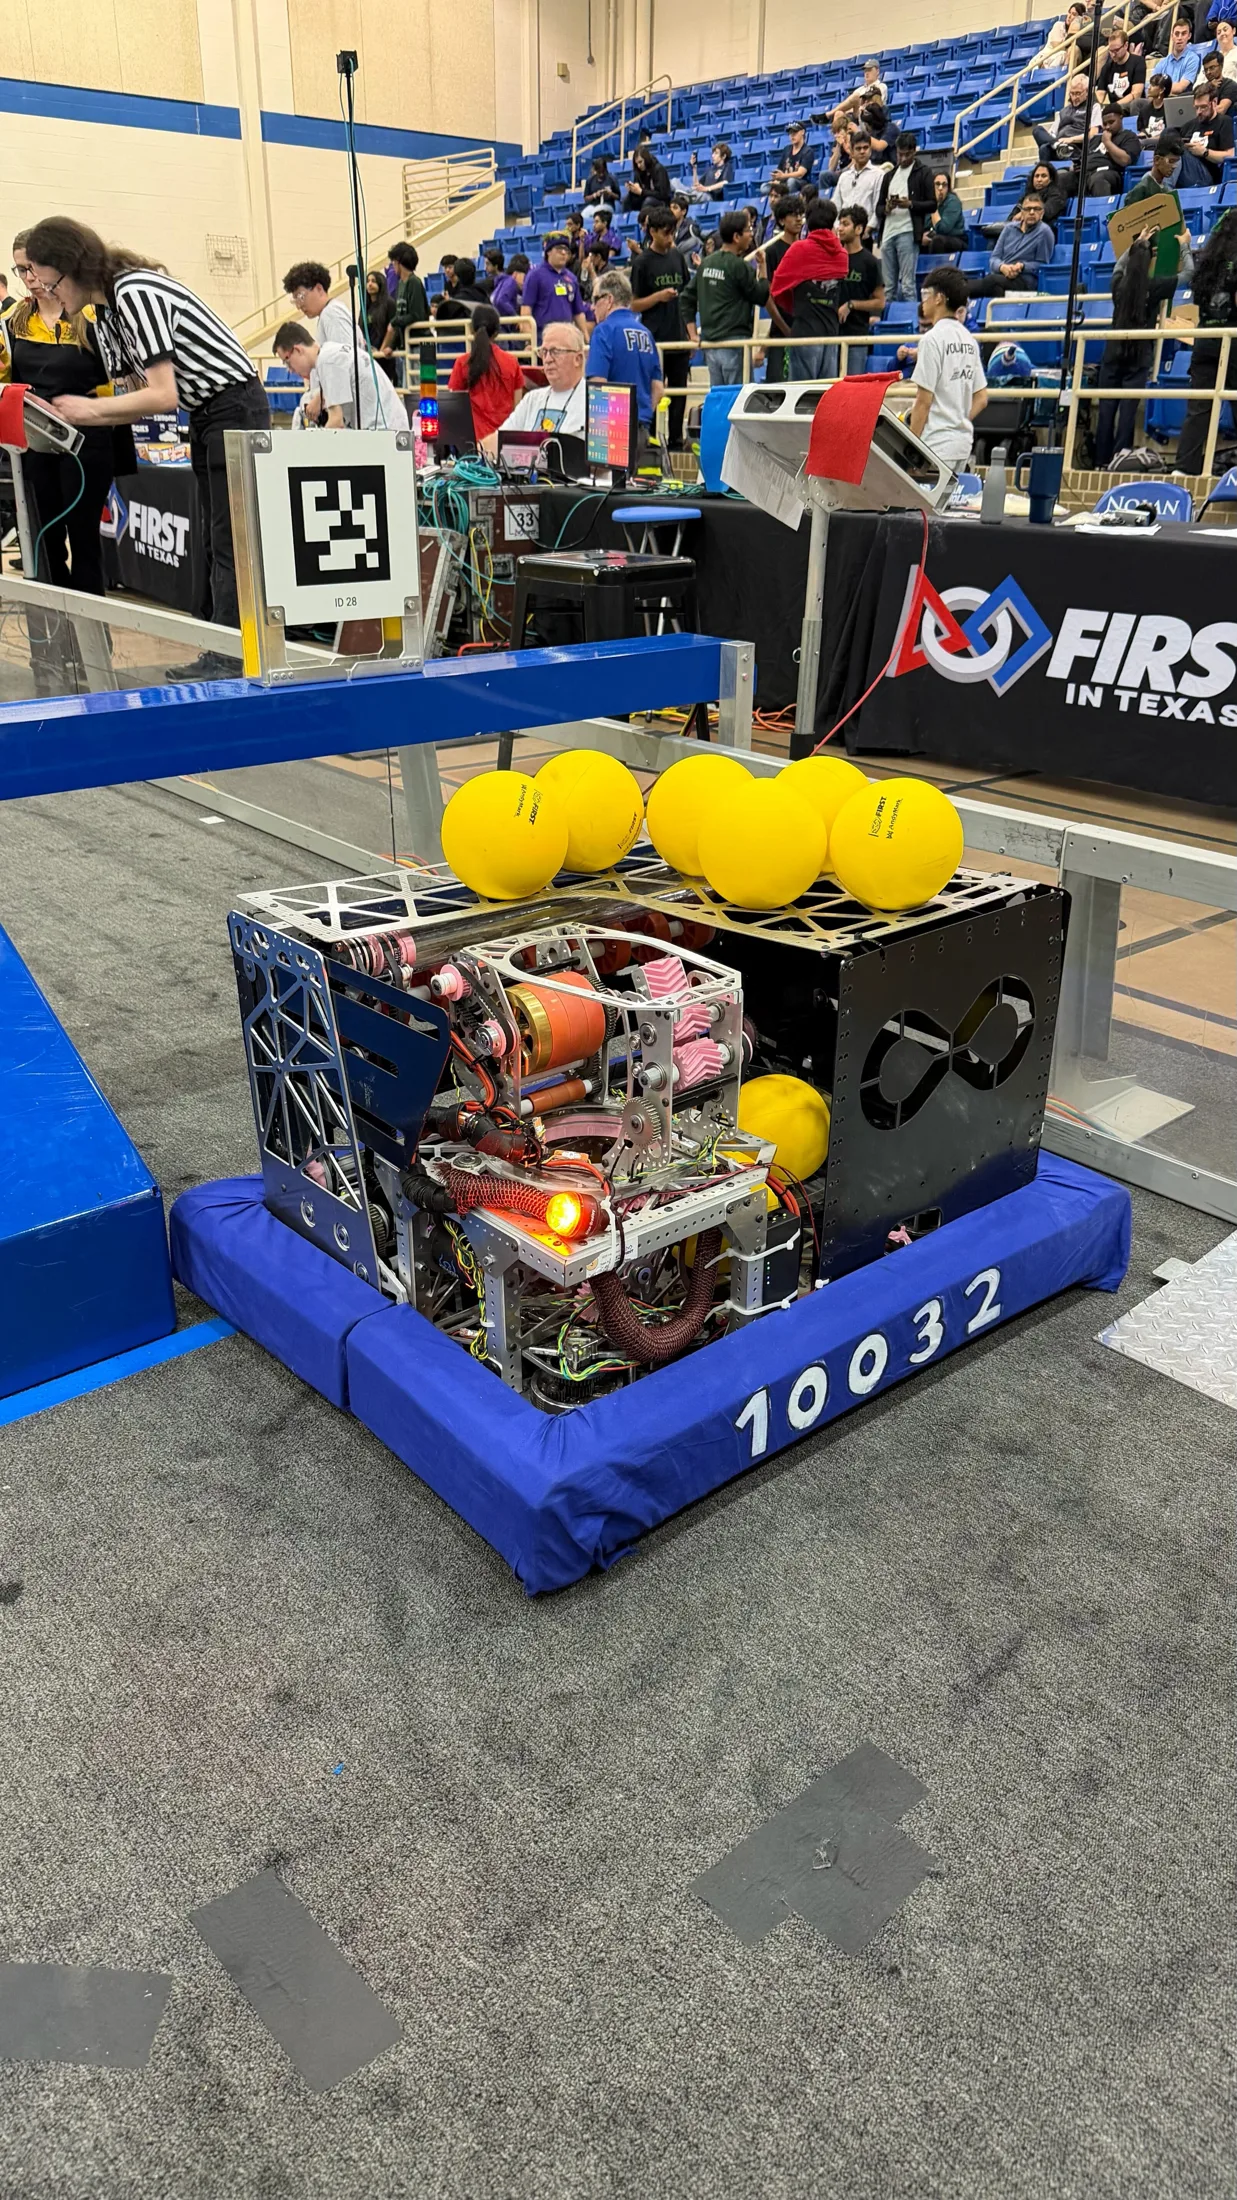
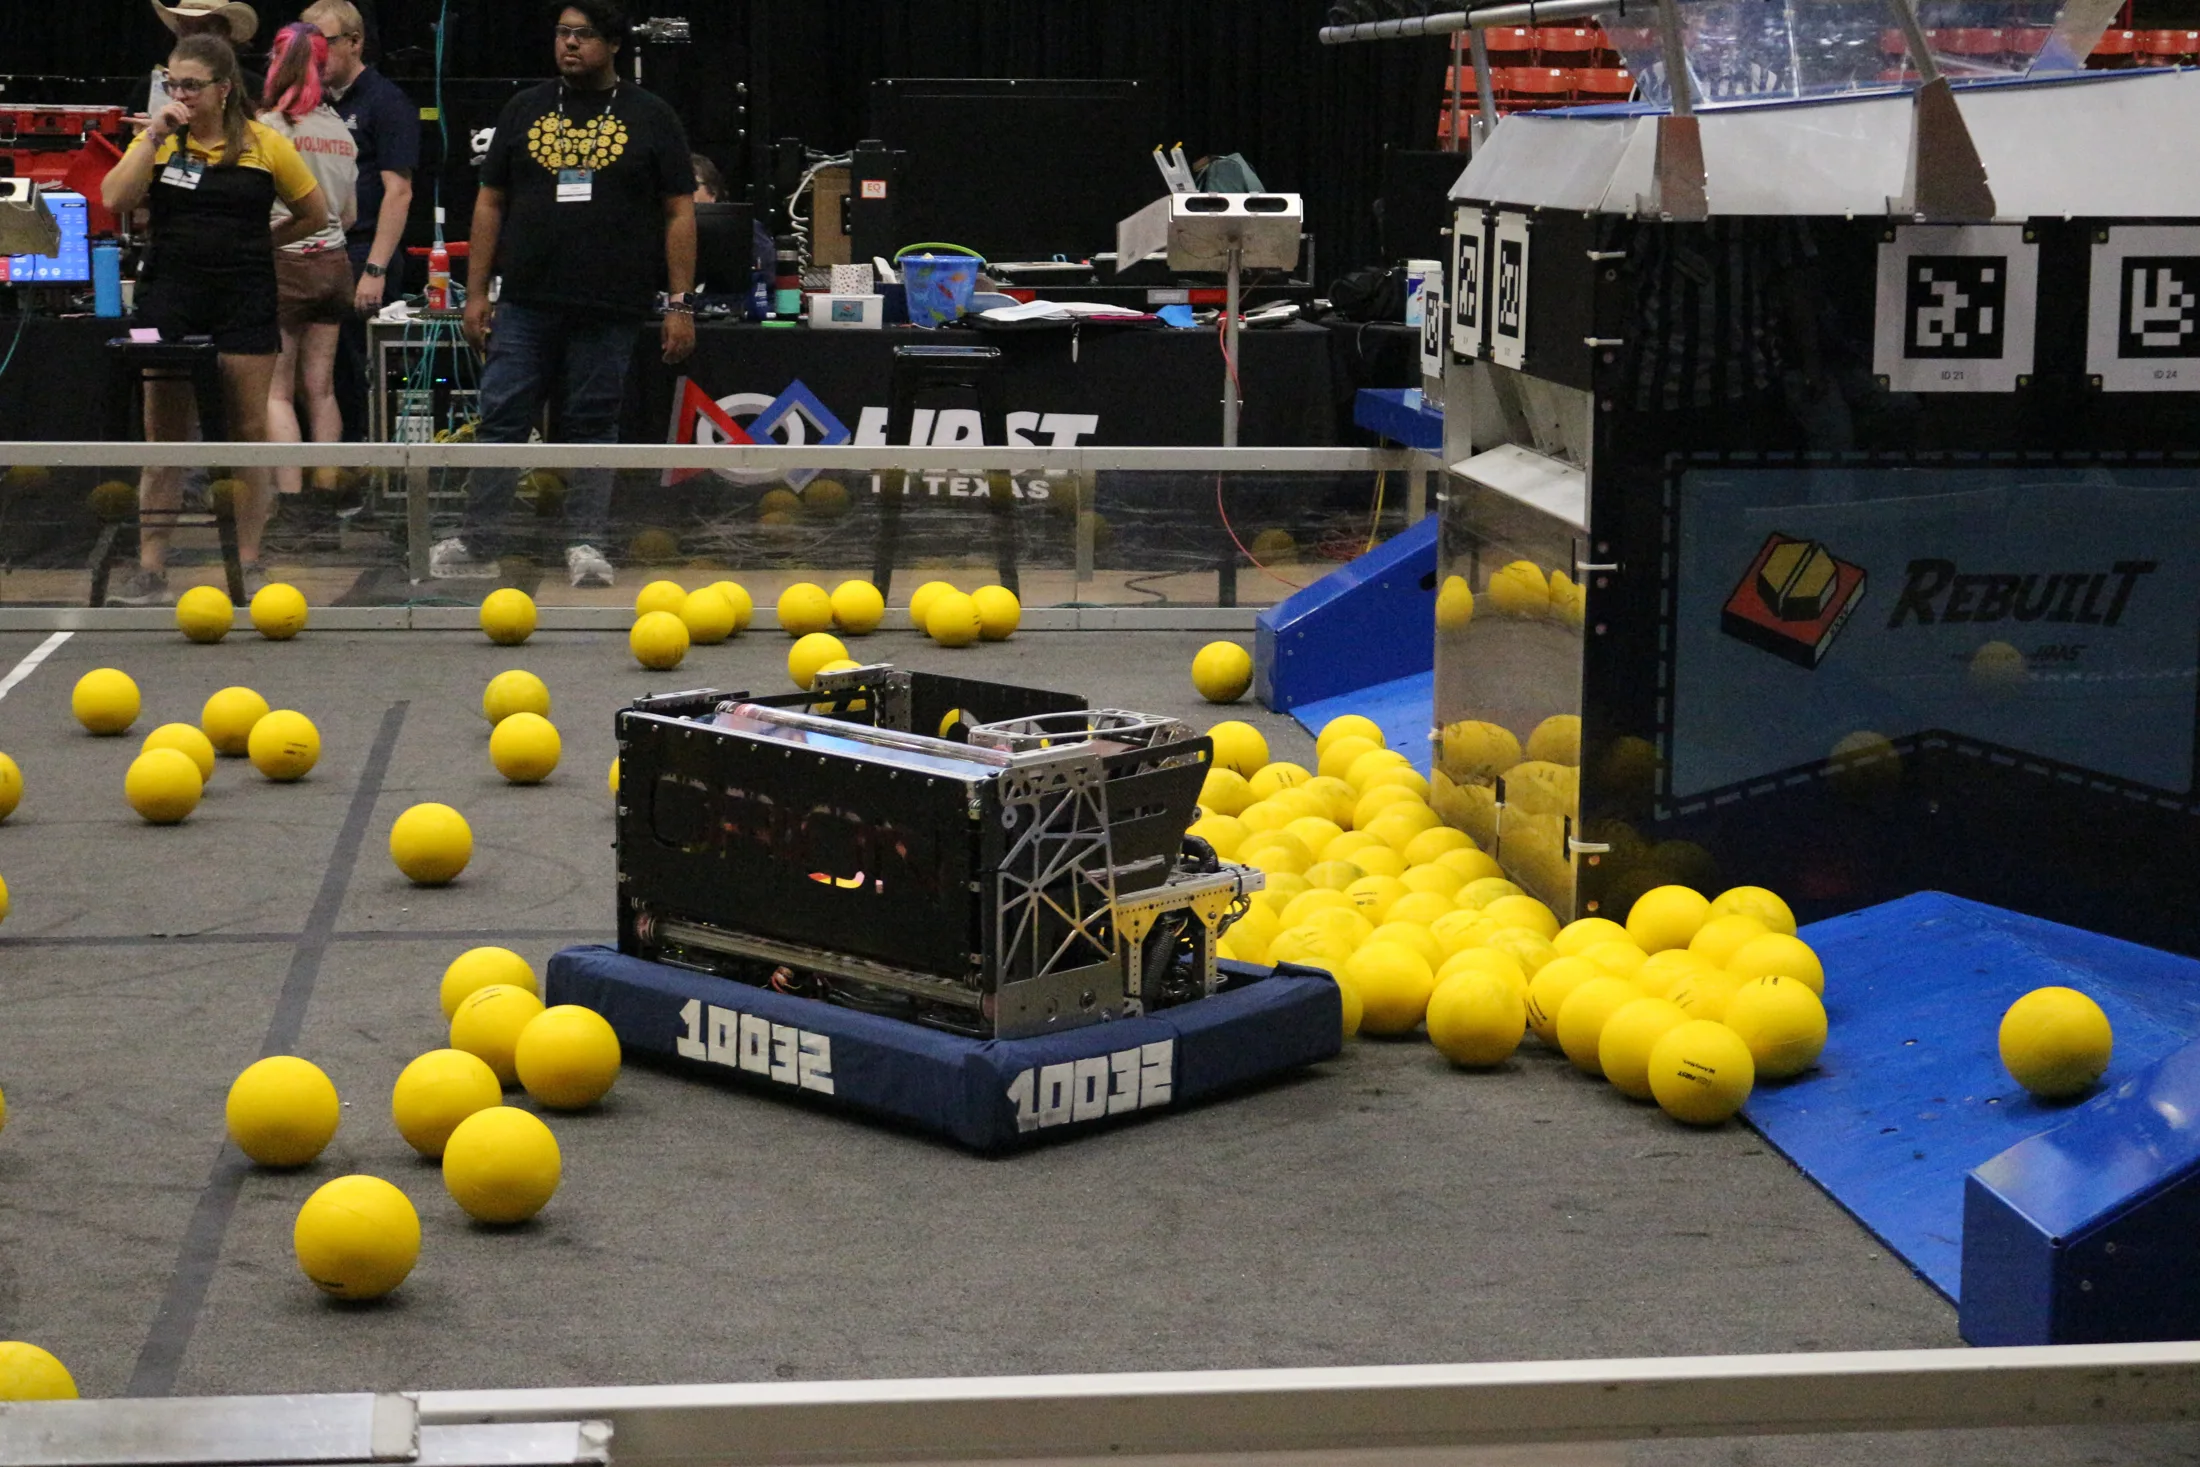
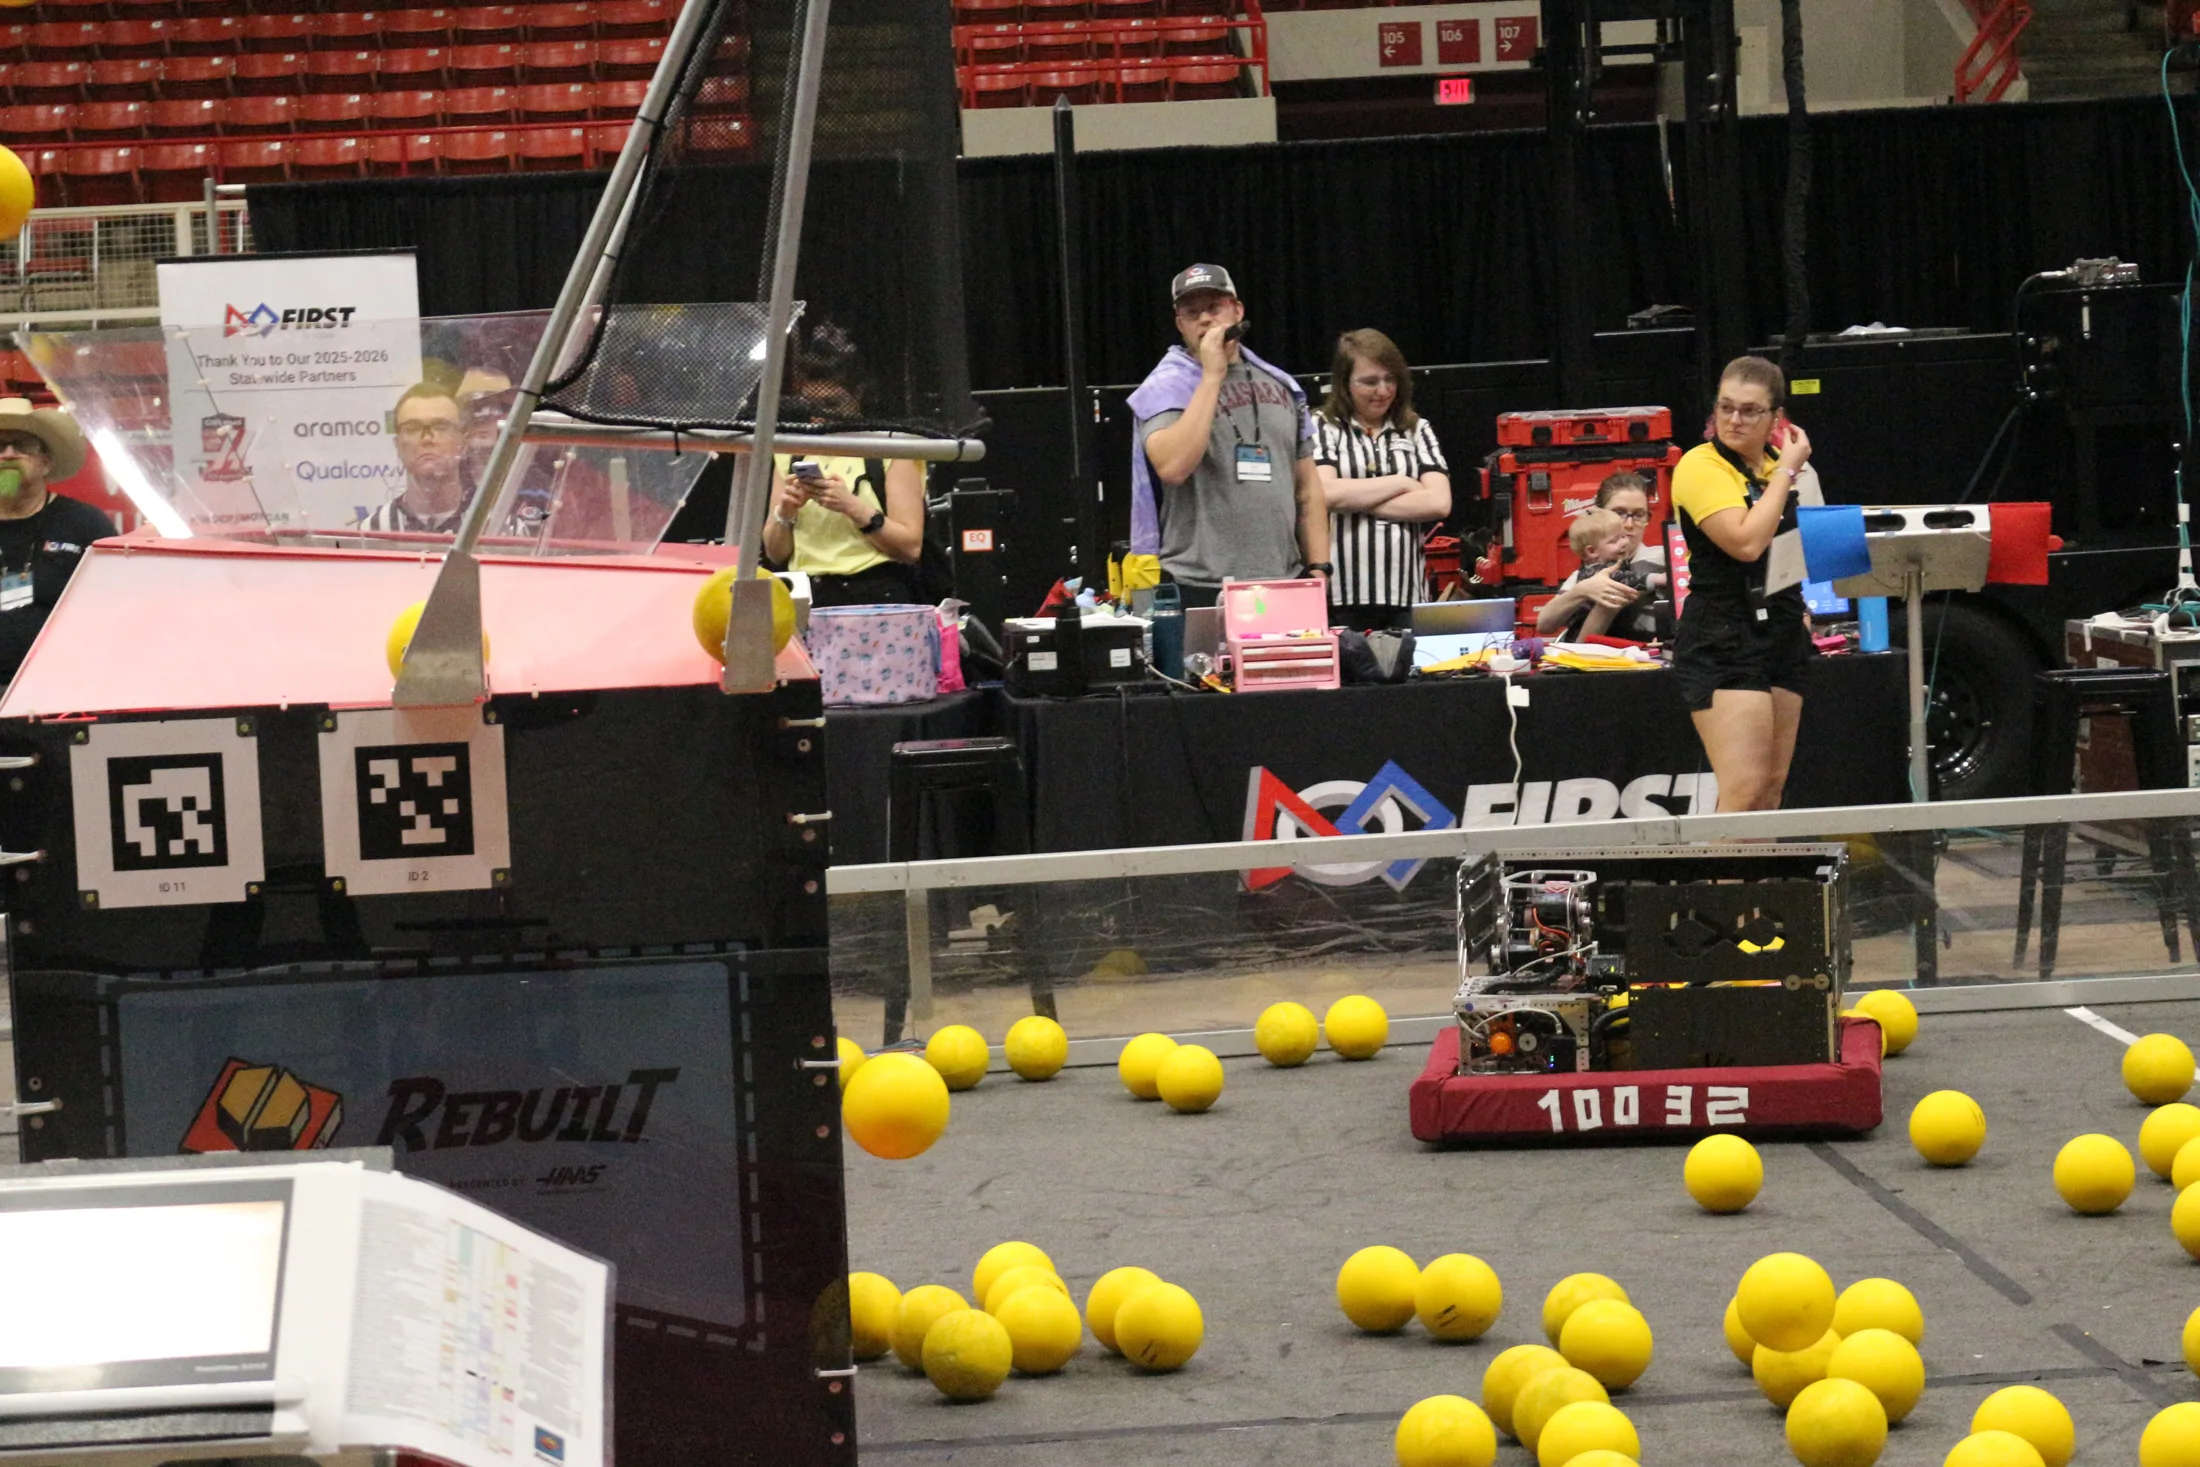
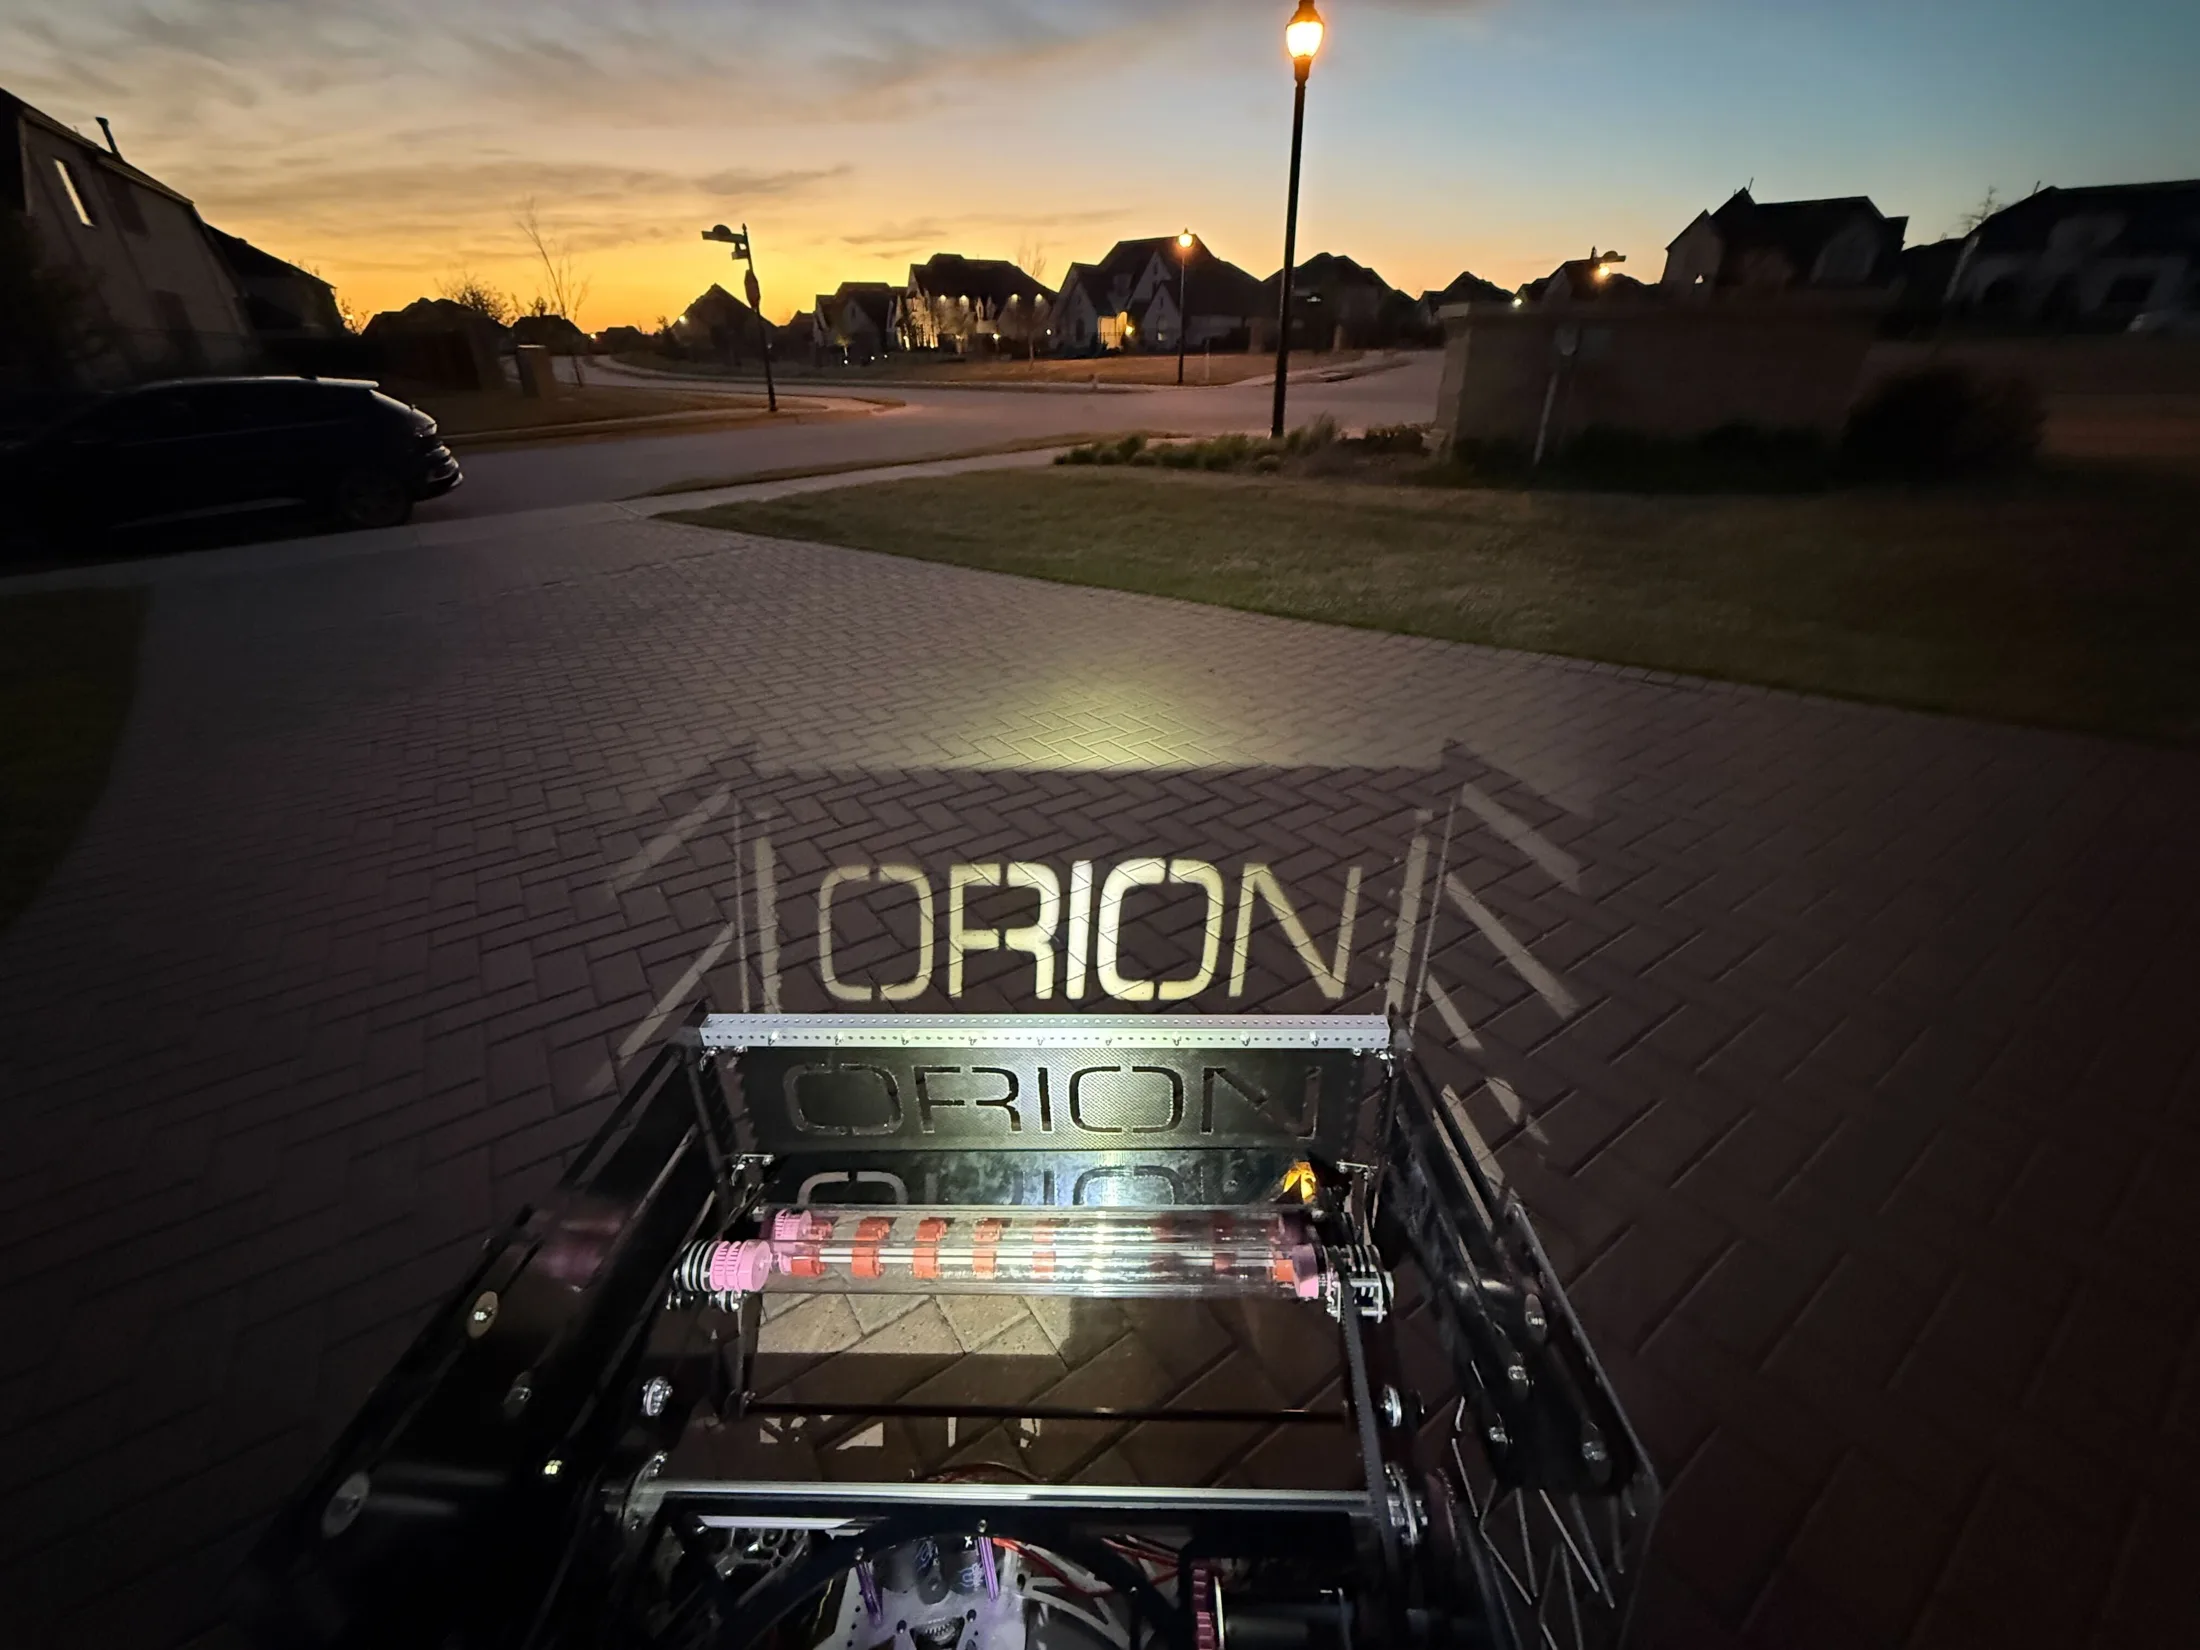
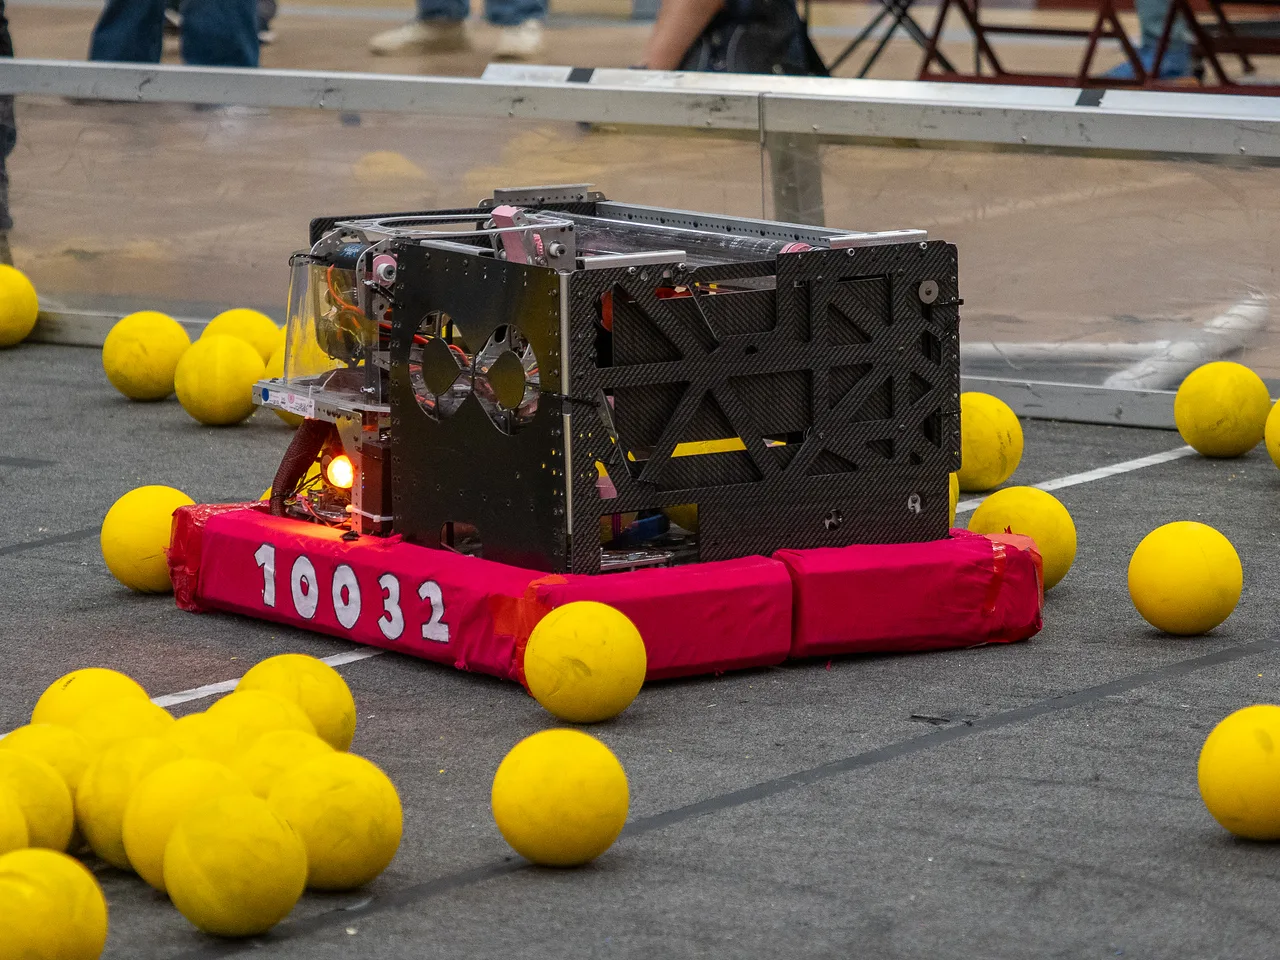
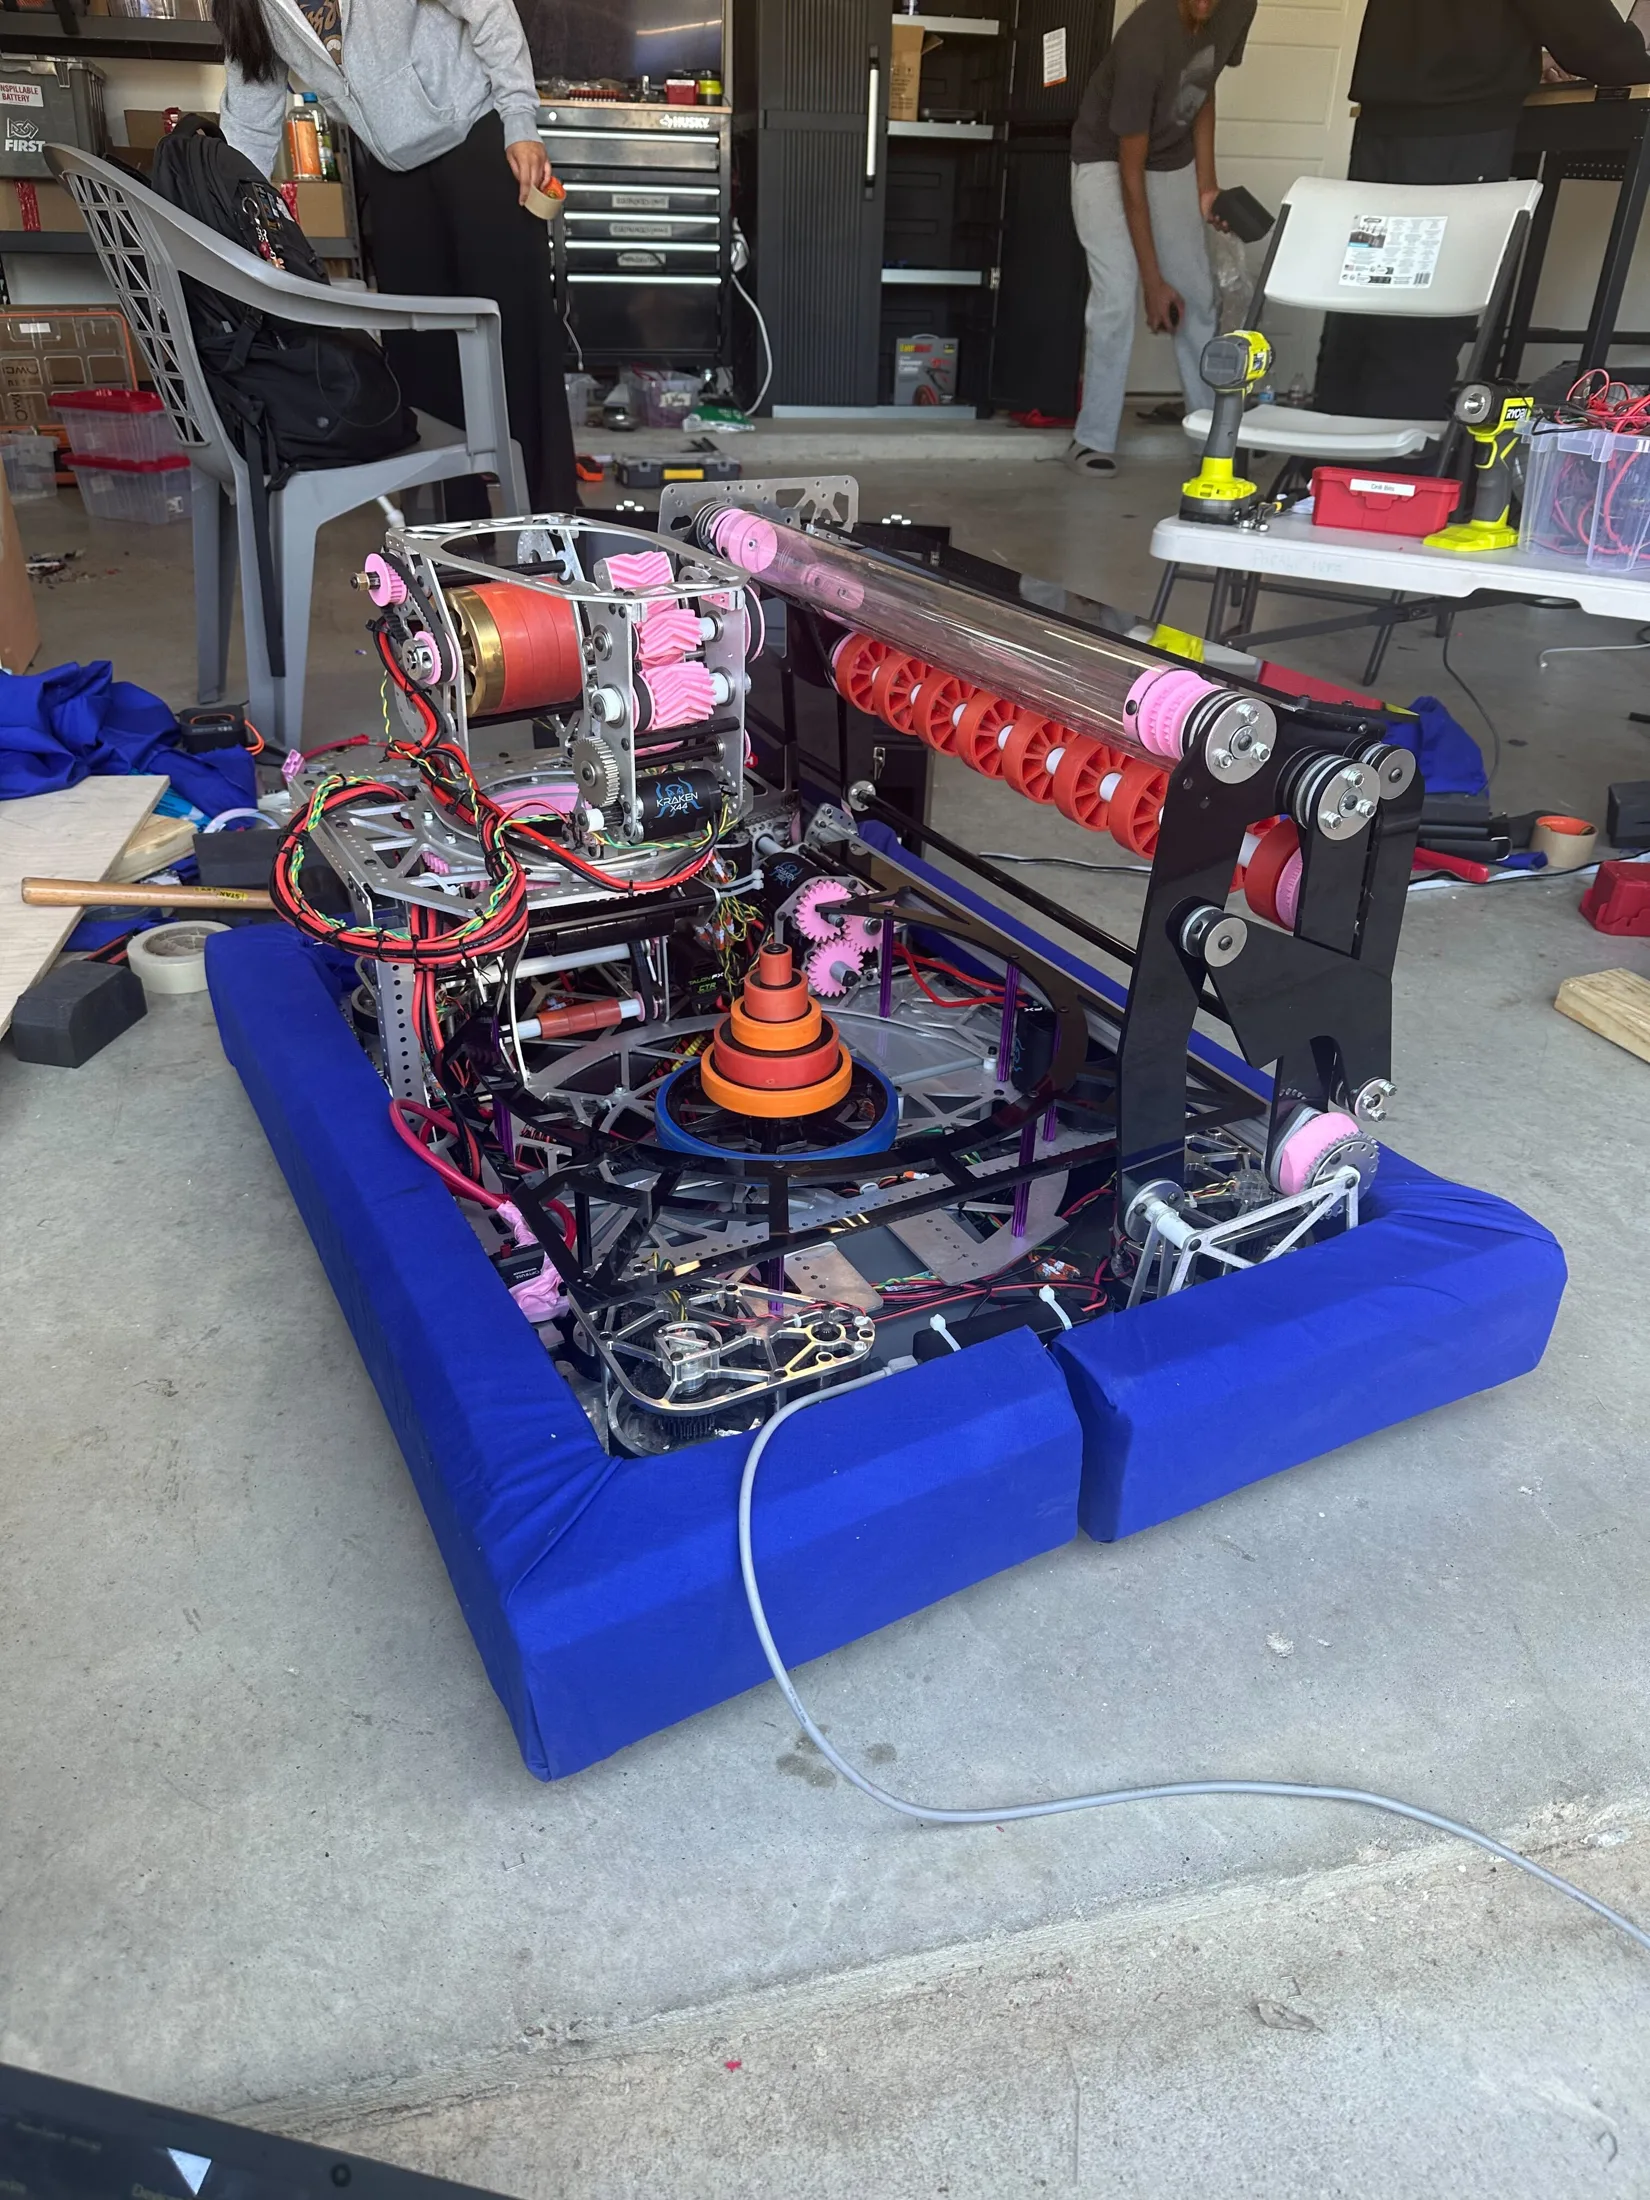
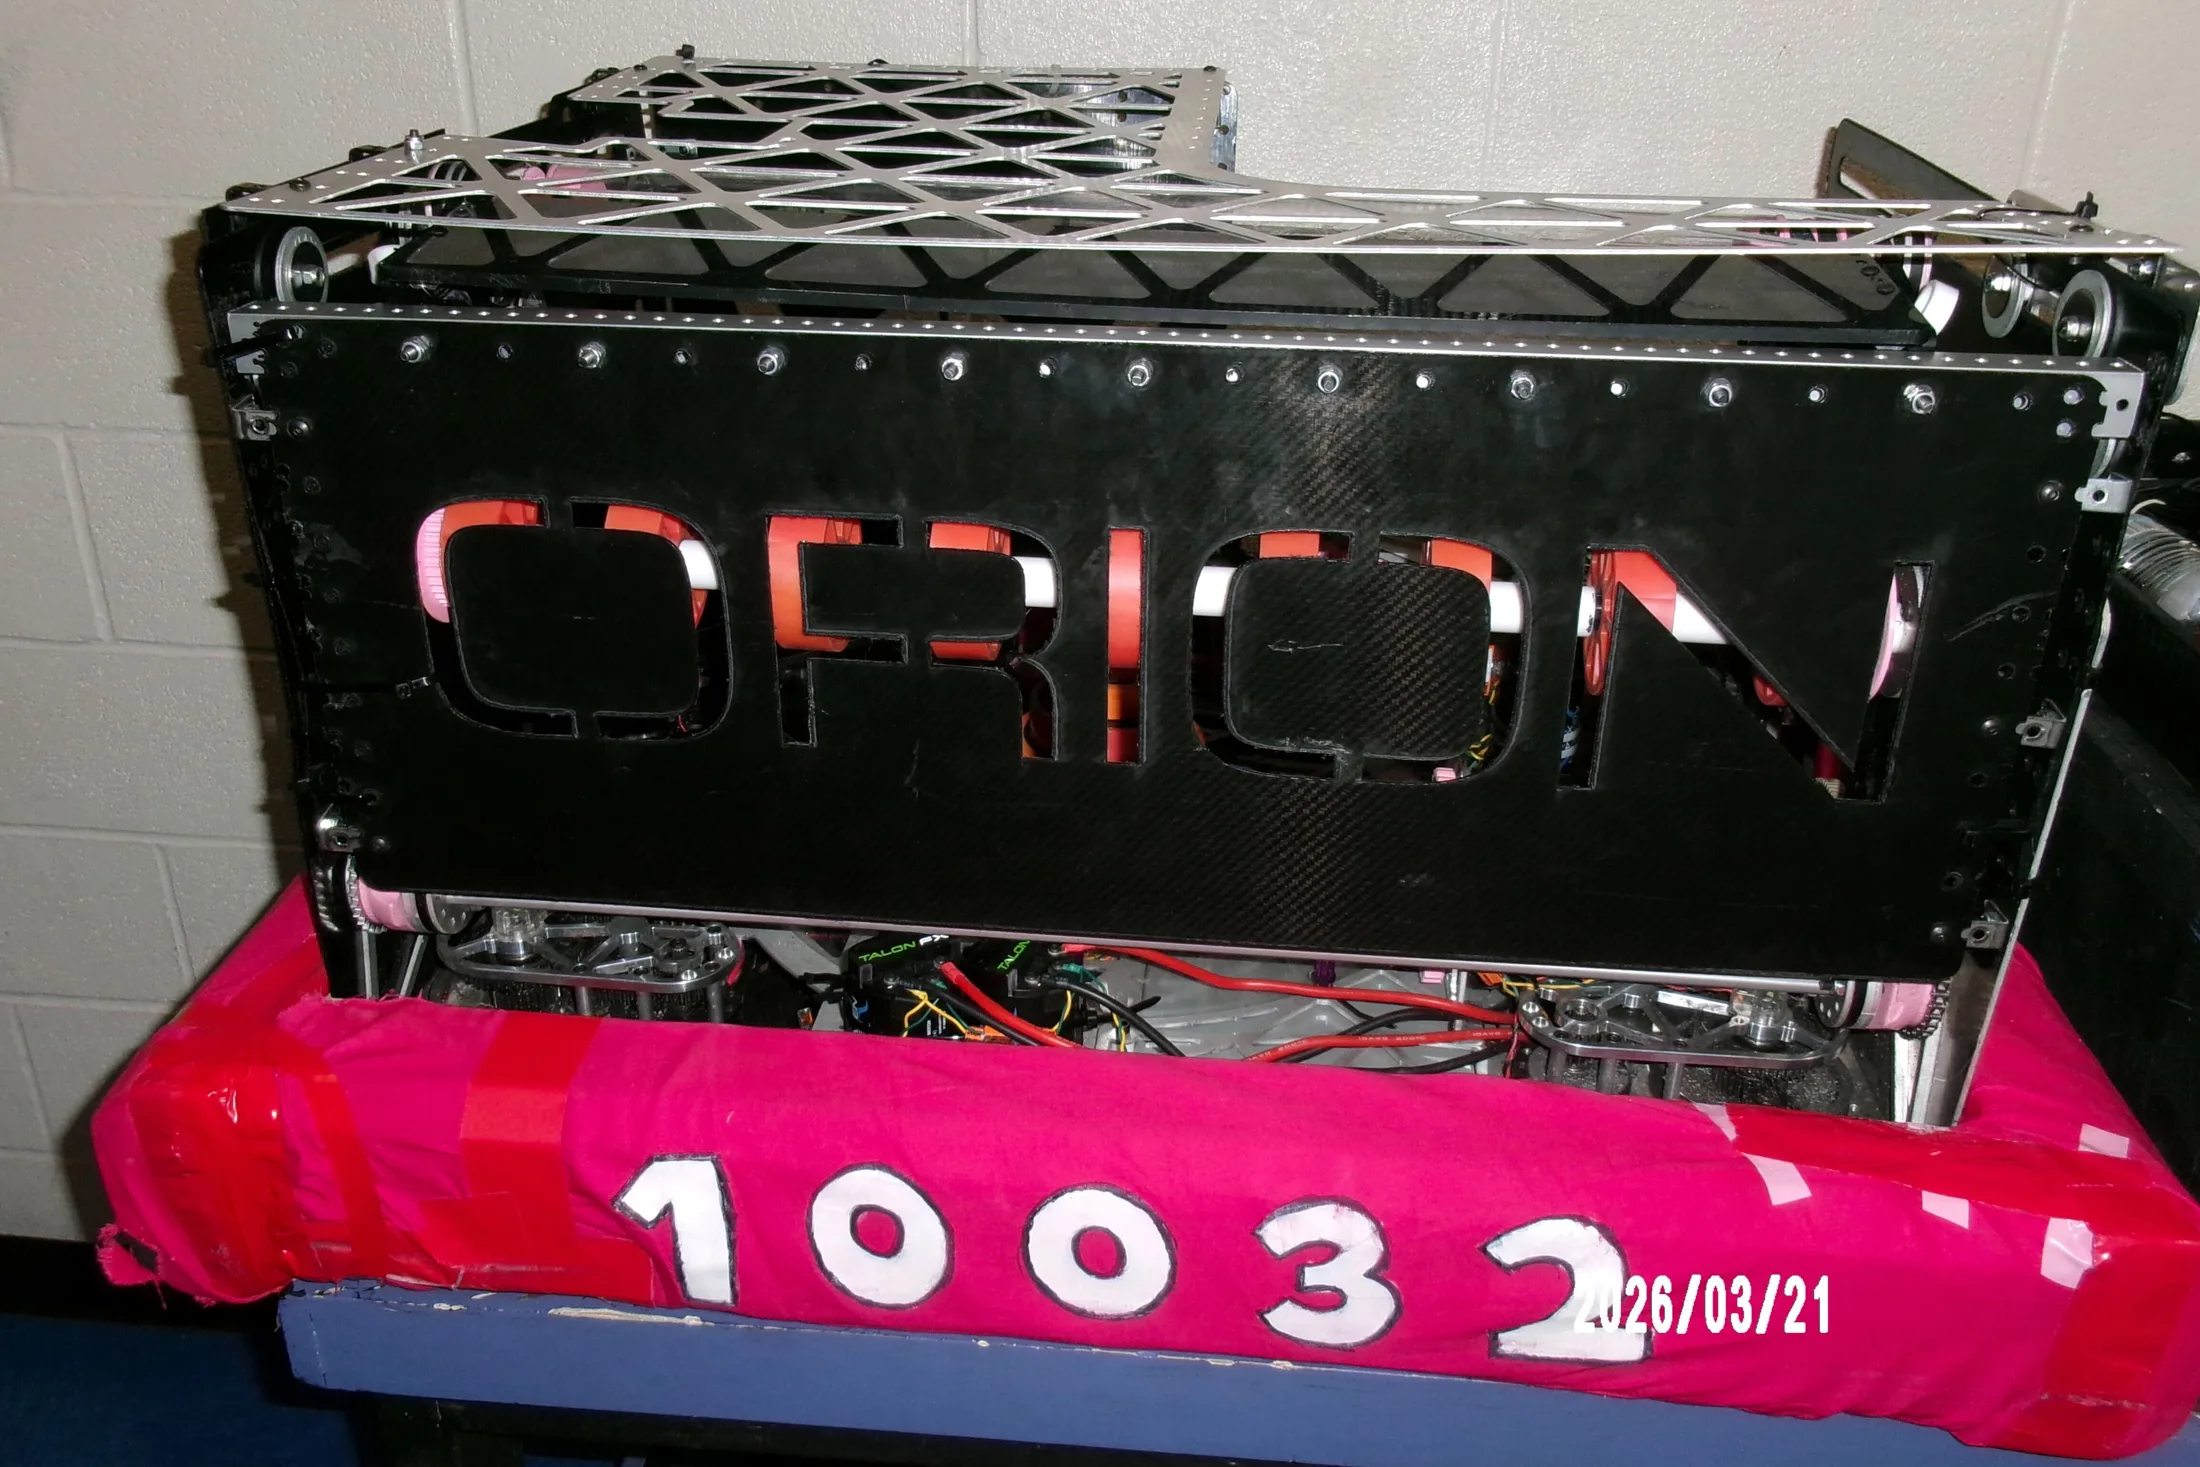
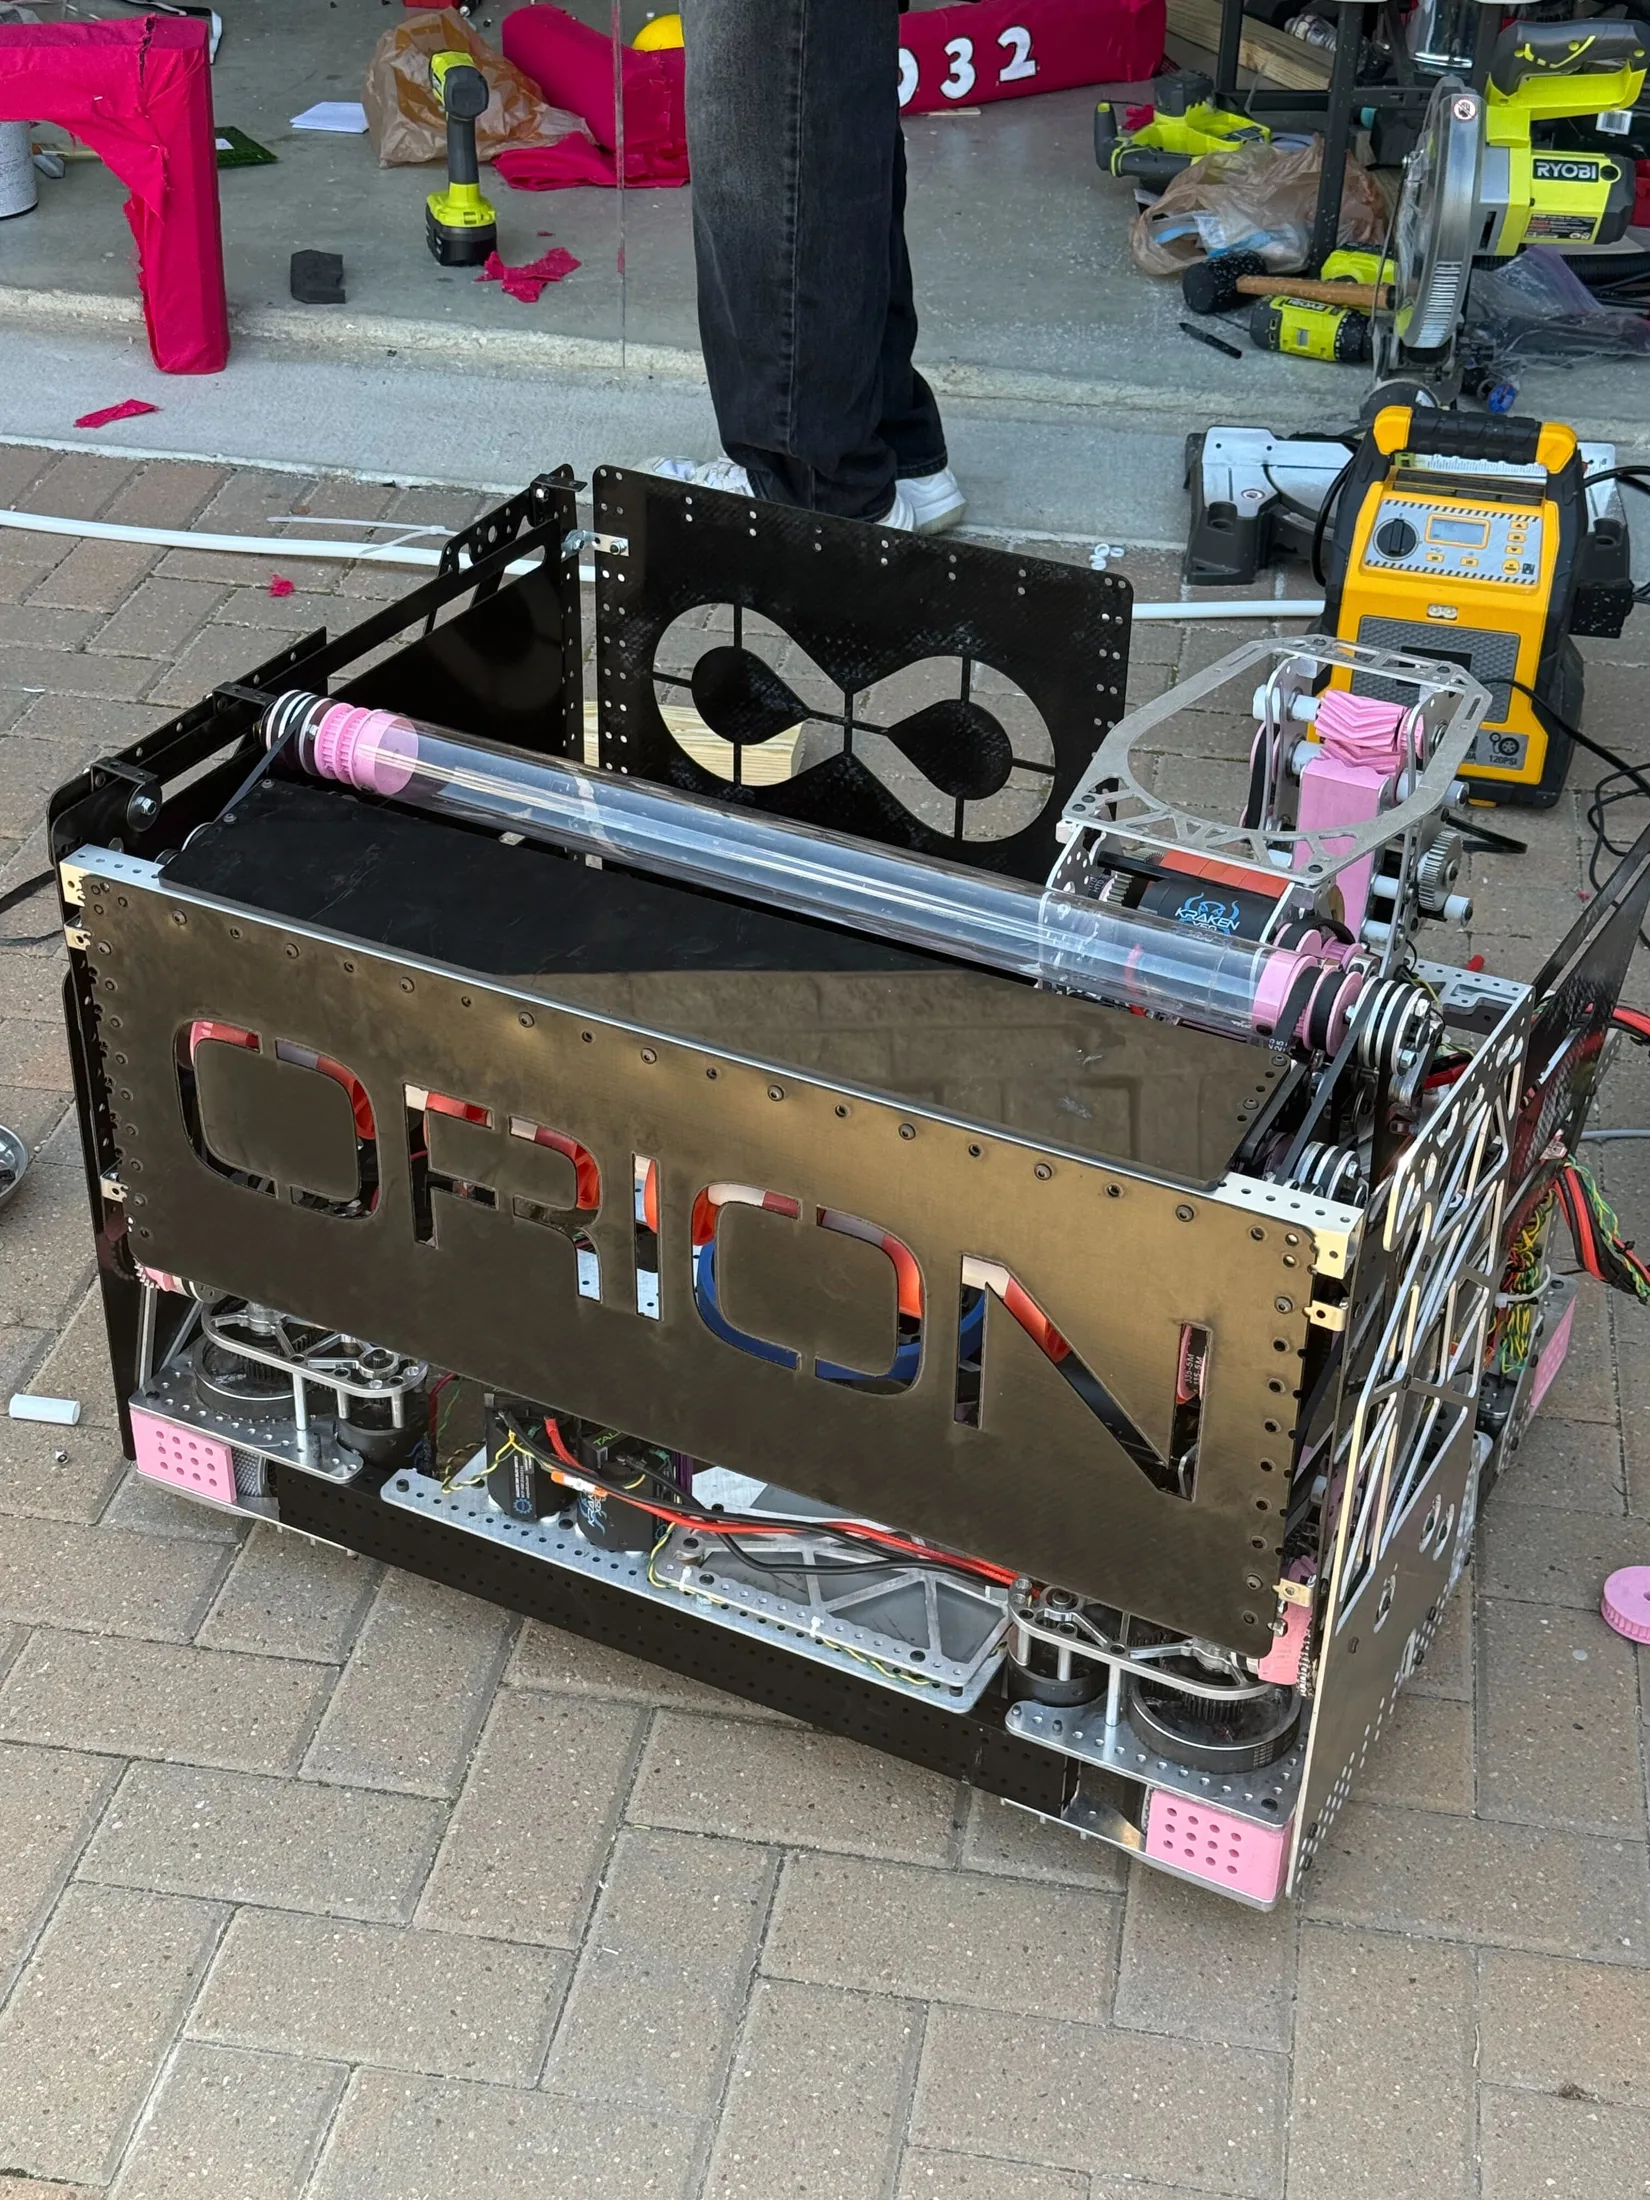
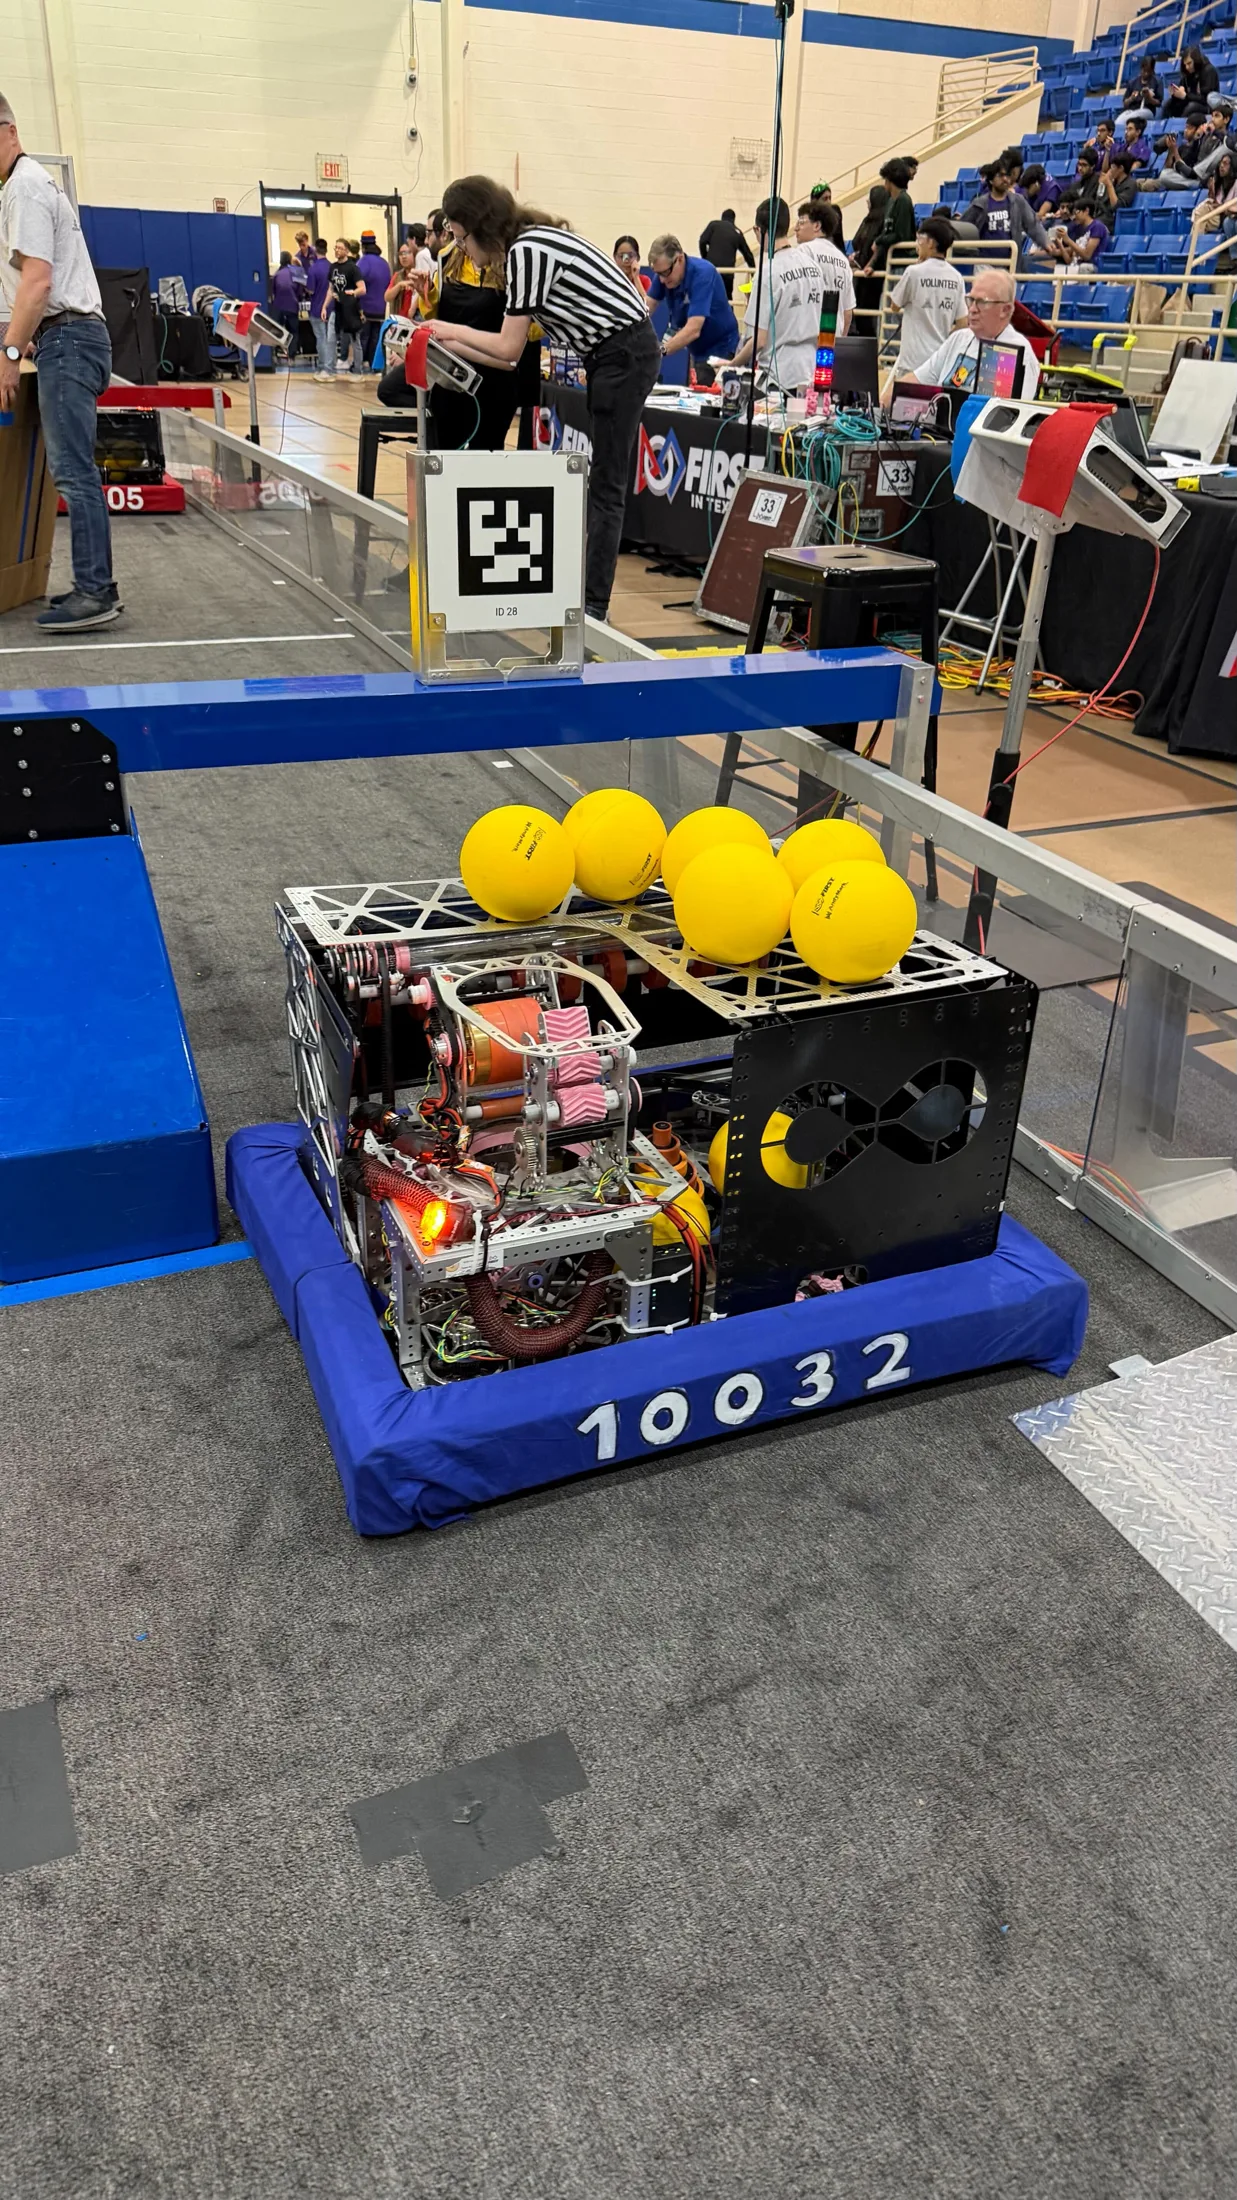
Our second-season robot. A four-module swerve drivebase carries a superstructure with the team name cut straight through the side panels. A roller intake at the back feeds a two-stage indexer, driven by HTD 5 mm belts and miter gears, that moves Fuel up through the robot.
01
Swerve drivebase
Four swerve modules on a lightened belly pan with MAXTube perimeter framing. 38 instances, 30 mates. The electronics layout (PDH, roboRIO, breaker mount) was resolved in CAD before parts were cut.
02
Roller intake
Belt-driven roller intake on MAXTube framing with plate side rails.
03
Indexer
Two stages, each its own sub-assembly with its own belt and chain part studio.
04
Superstructure
22 instances, bolts to the drivebase, houses the indexer.
The lesson from year one was to finish mechanical earlier so programming gets more time. We made that the priority, and it helped us win our first competition. For the second event we focused on an autonomous mode.
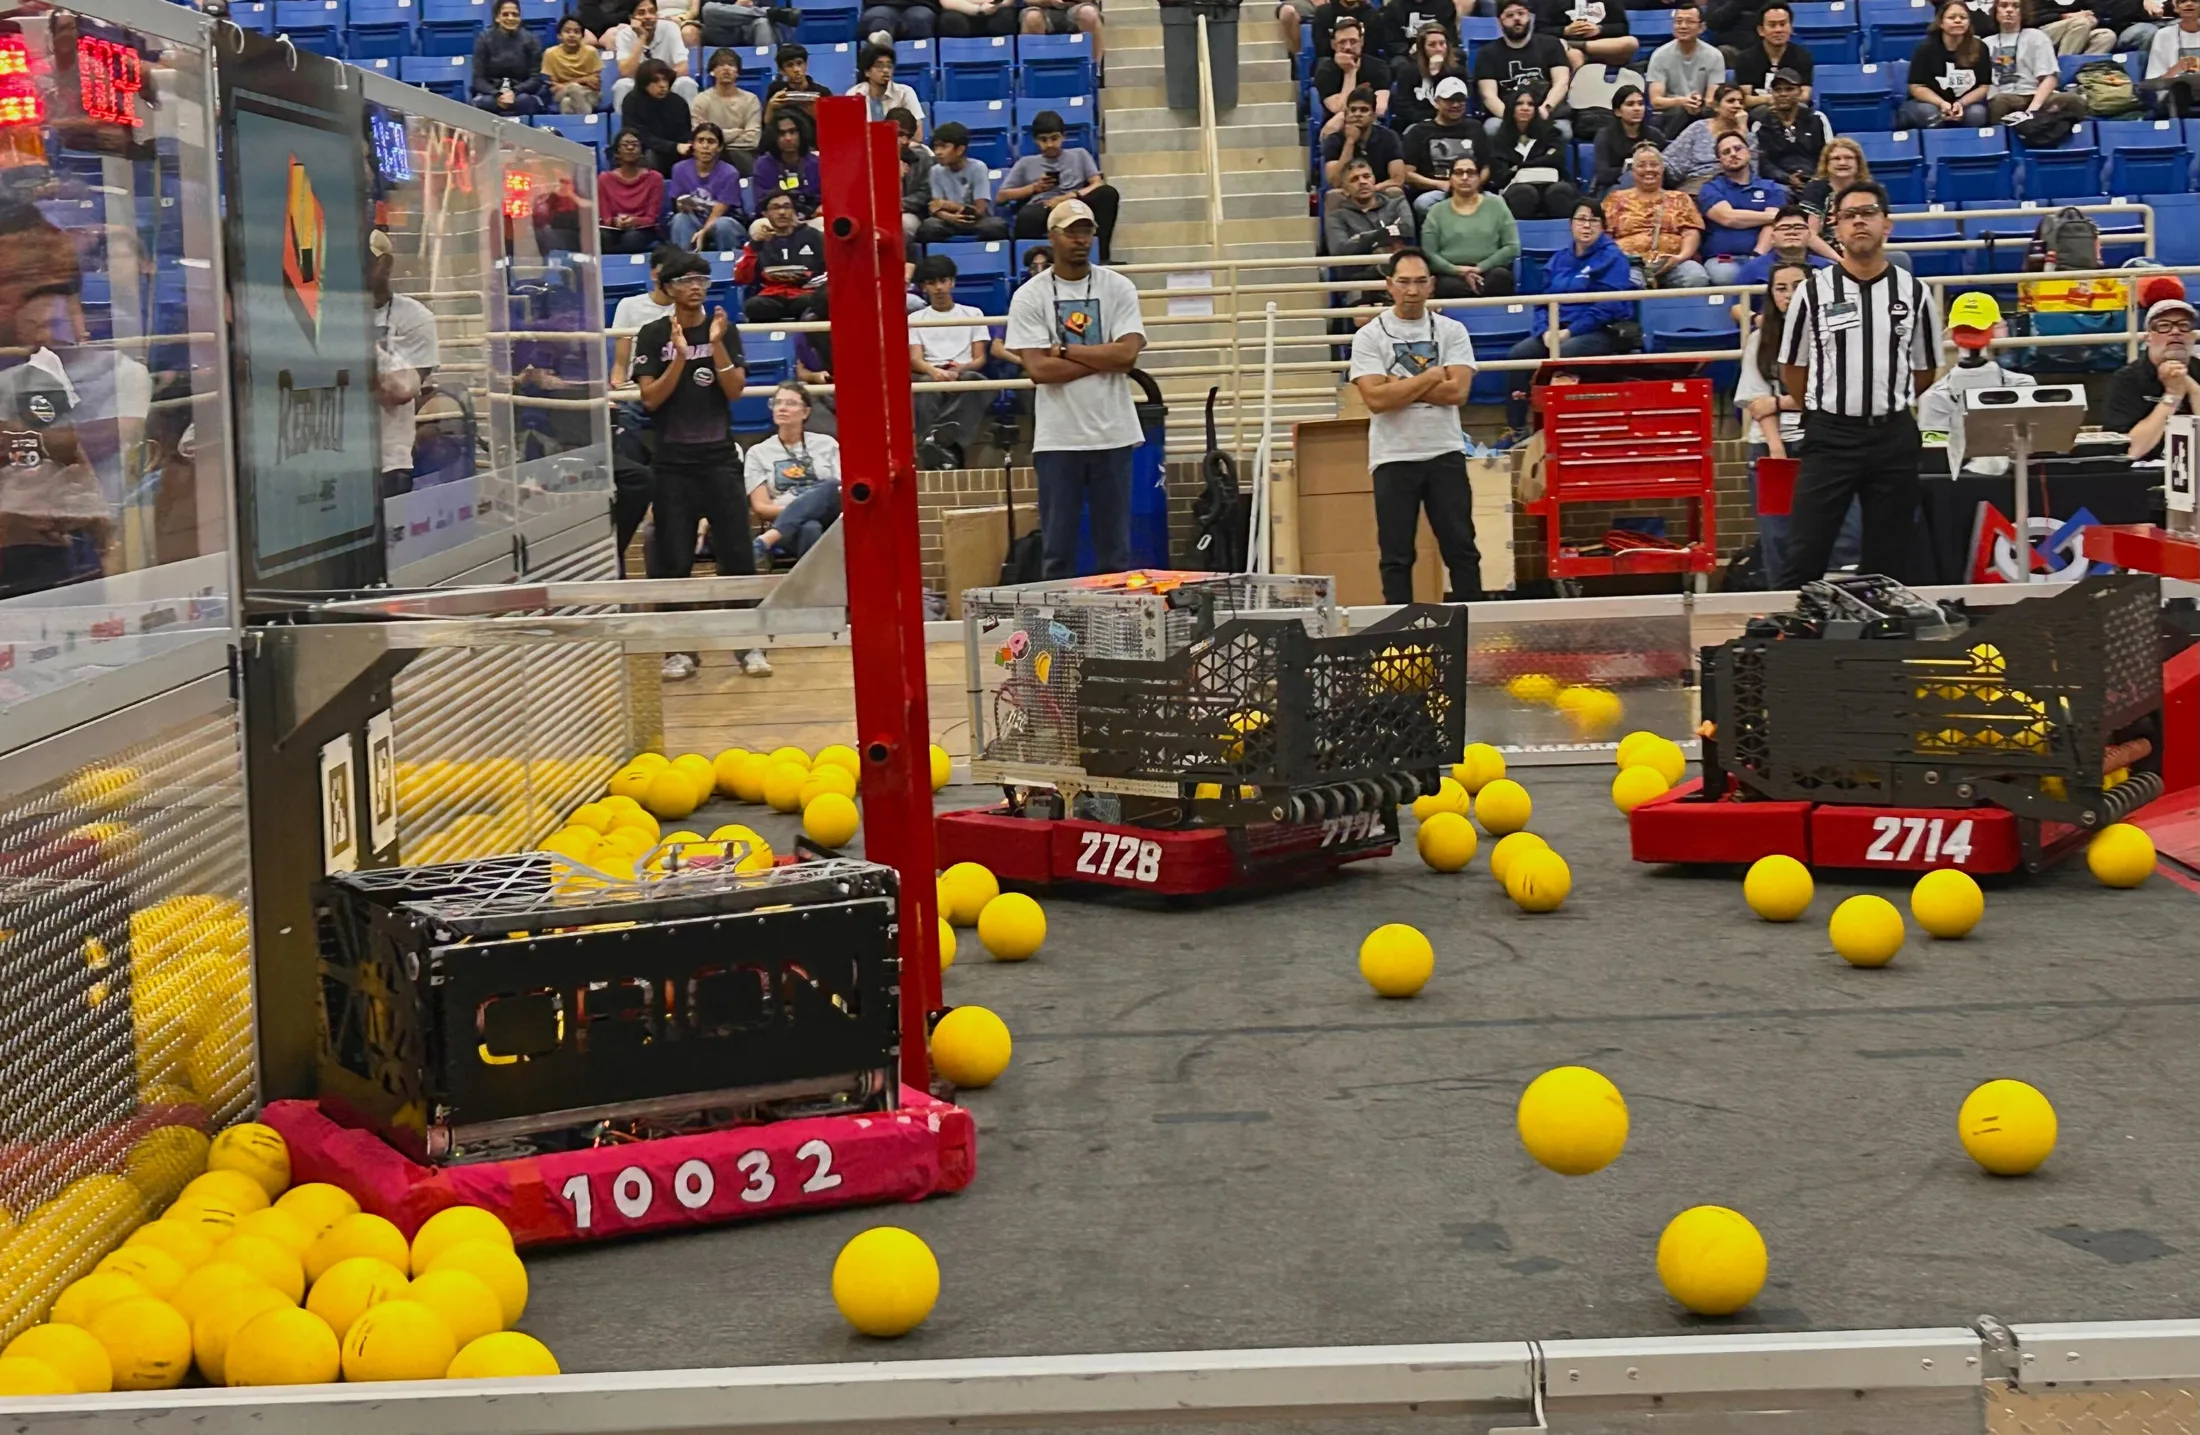
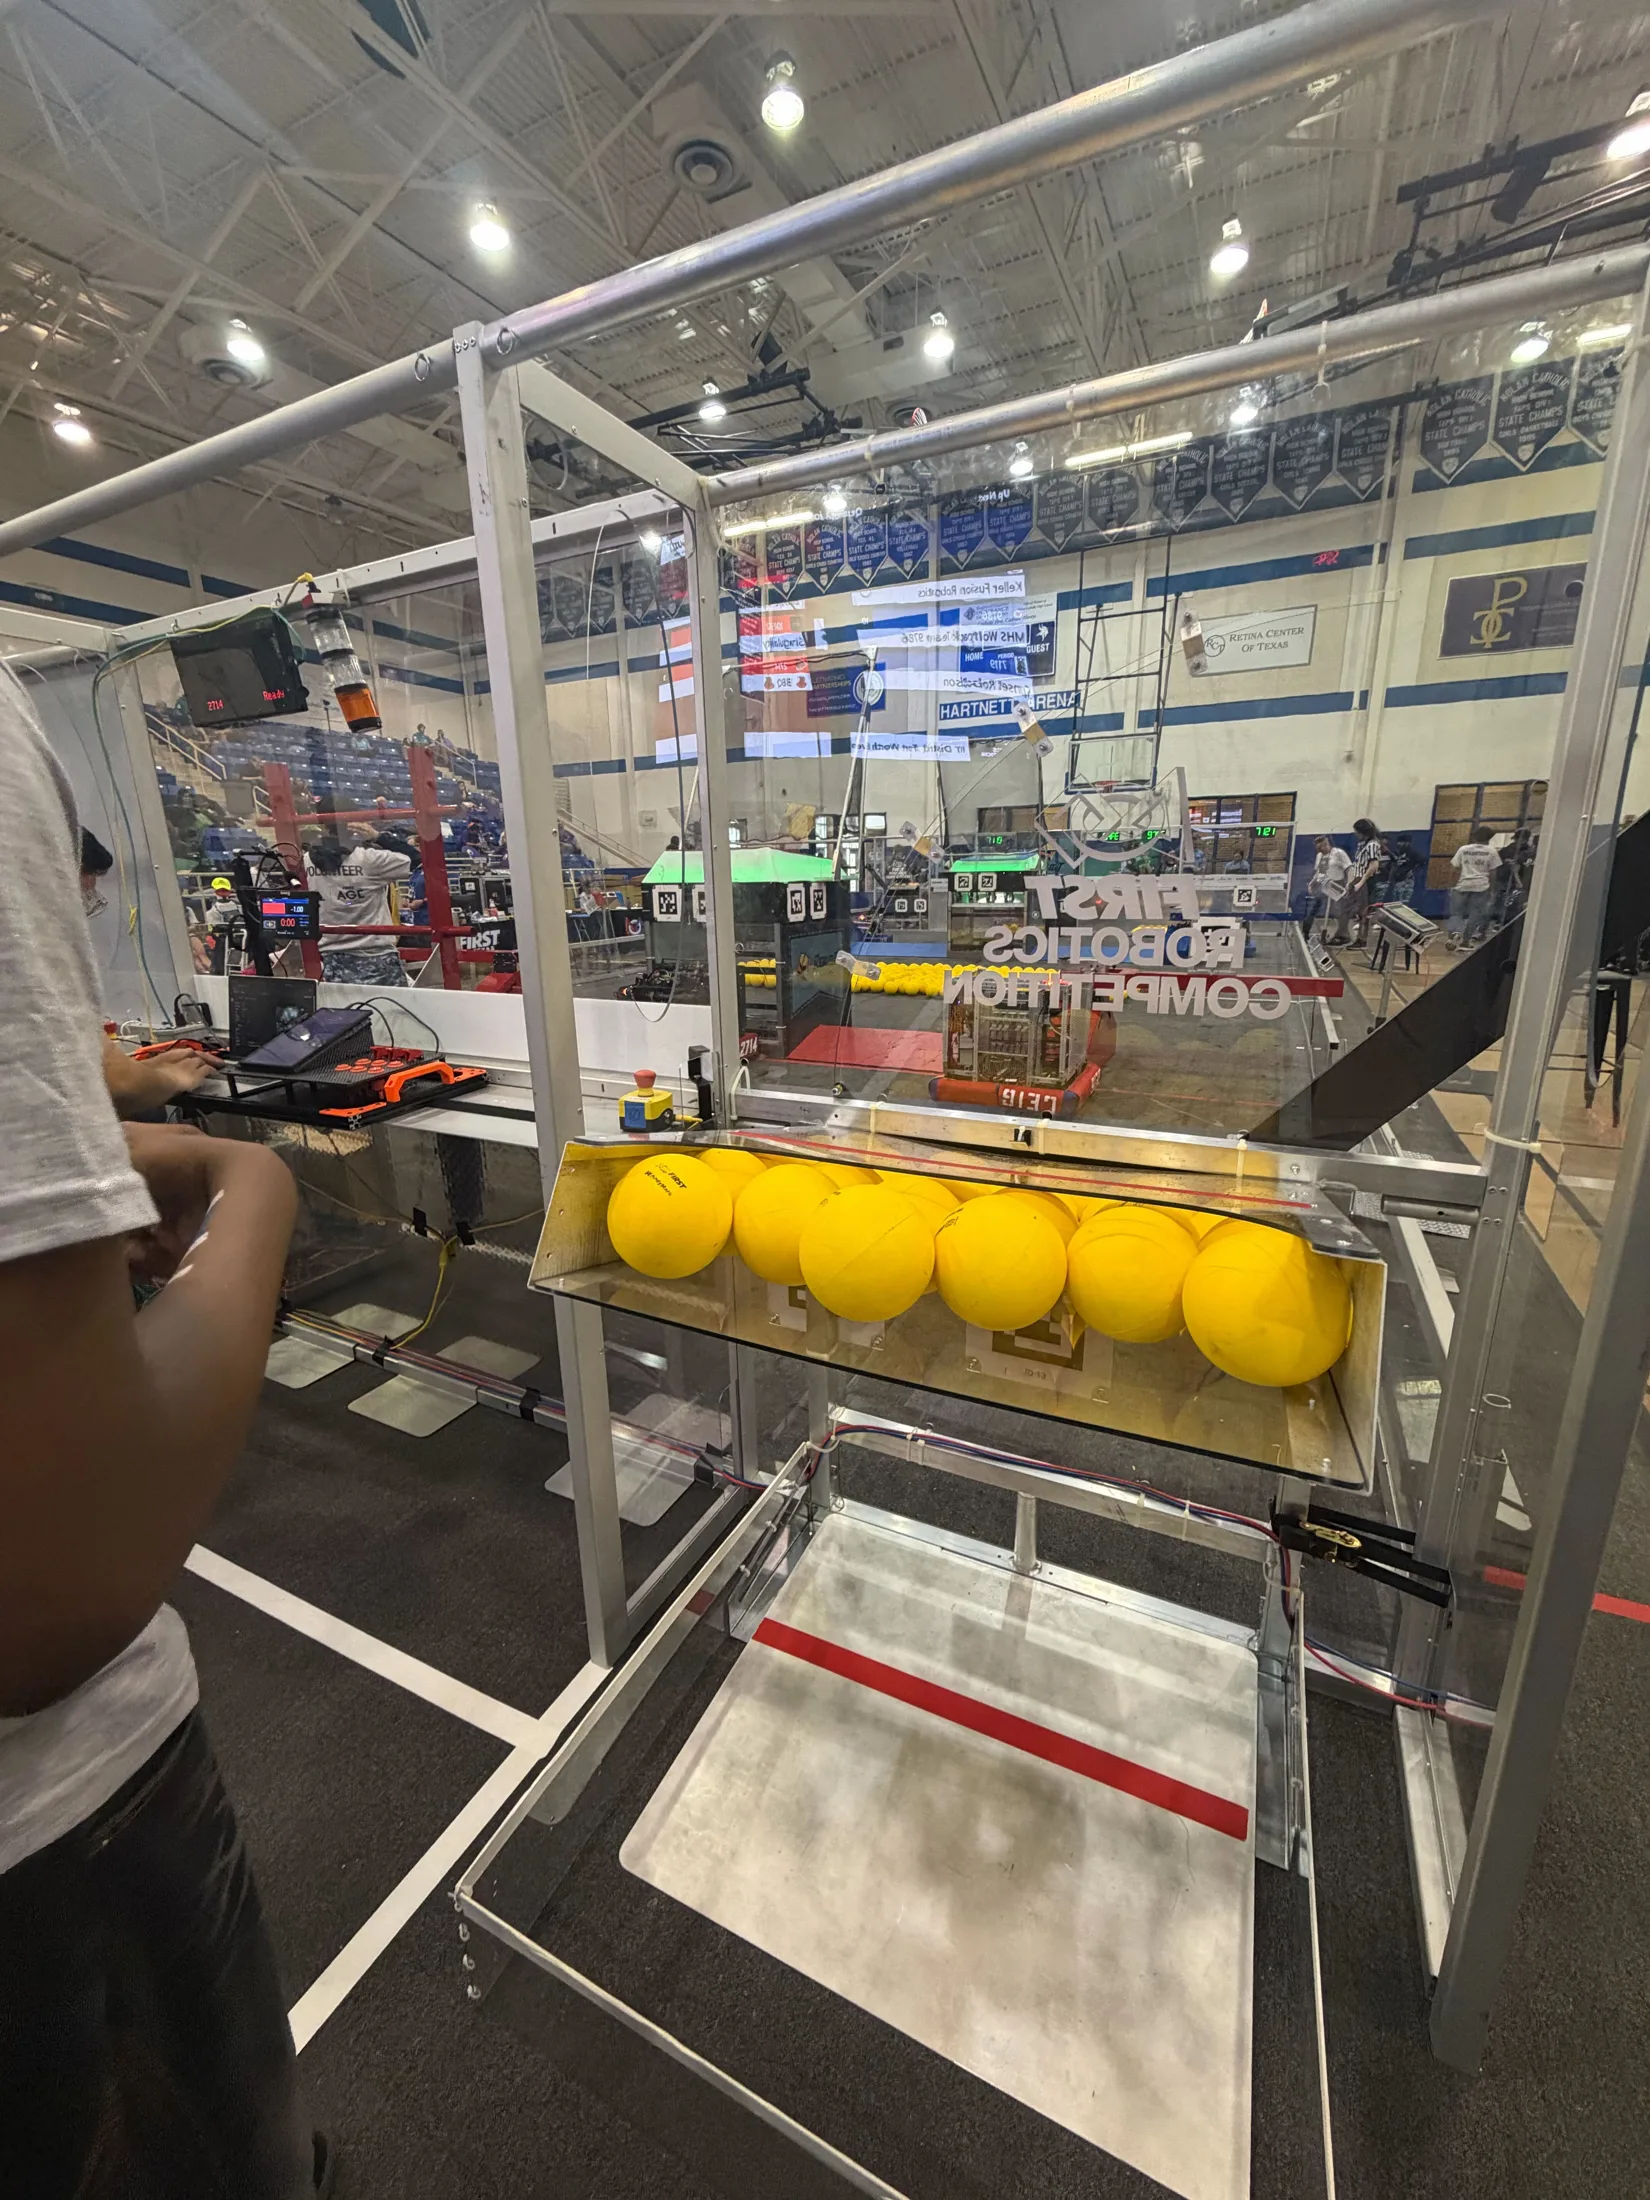
ORION on the field
2025 robot
2025 · REEFSCAPE
Rookie year, Worlds qualifier
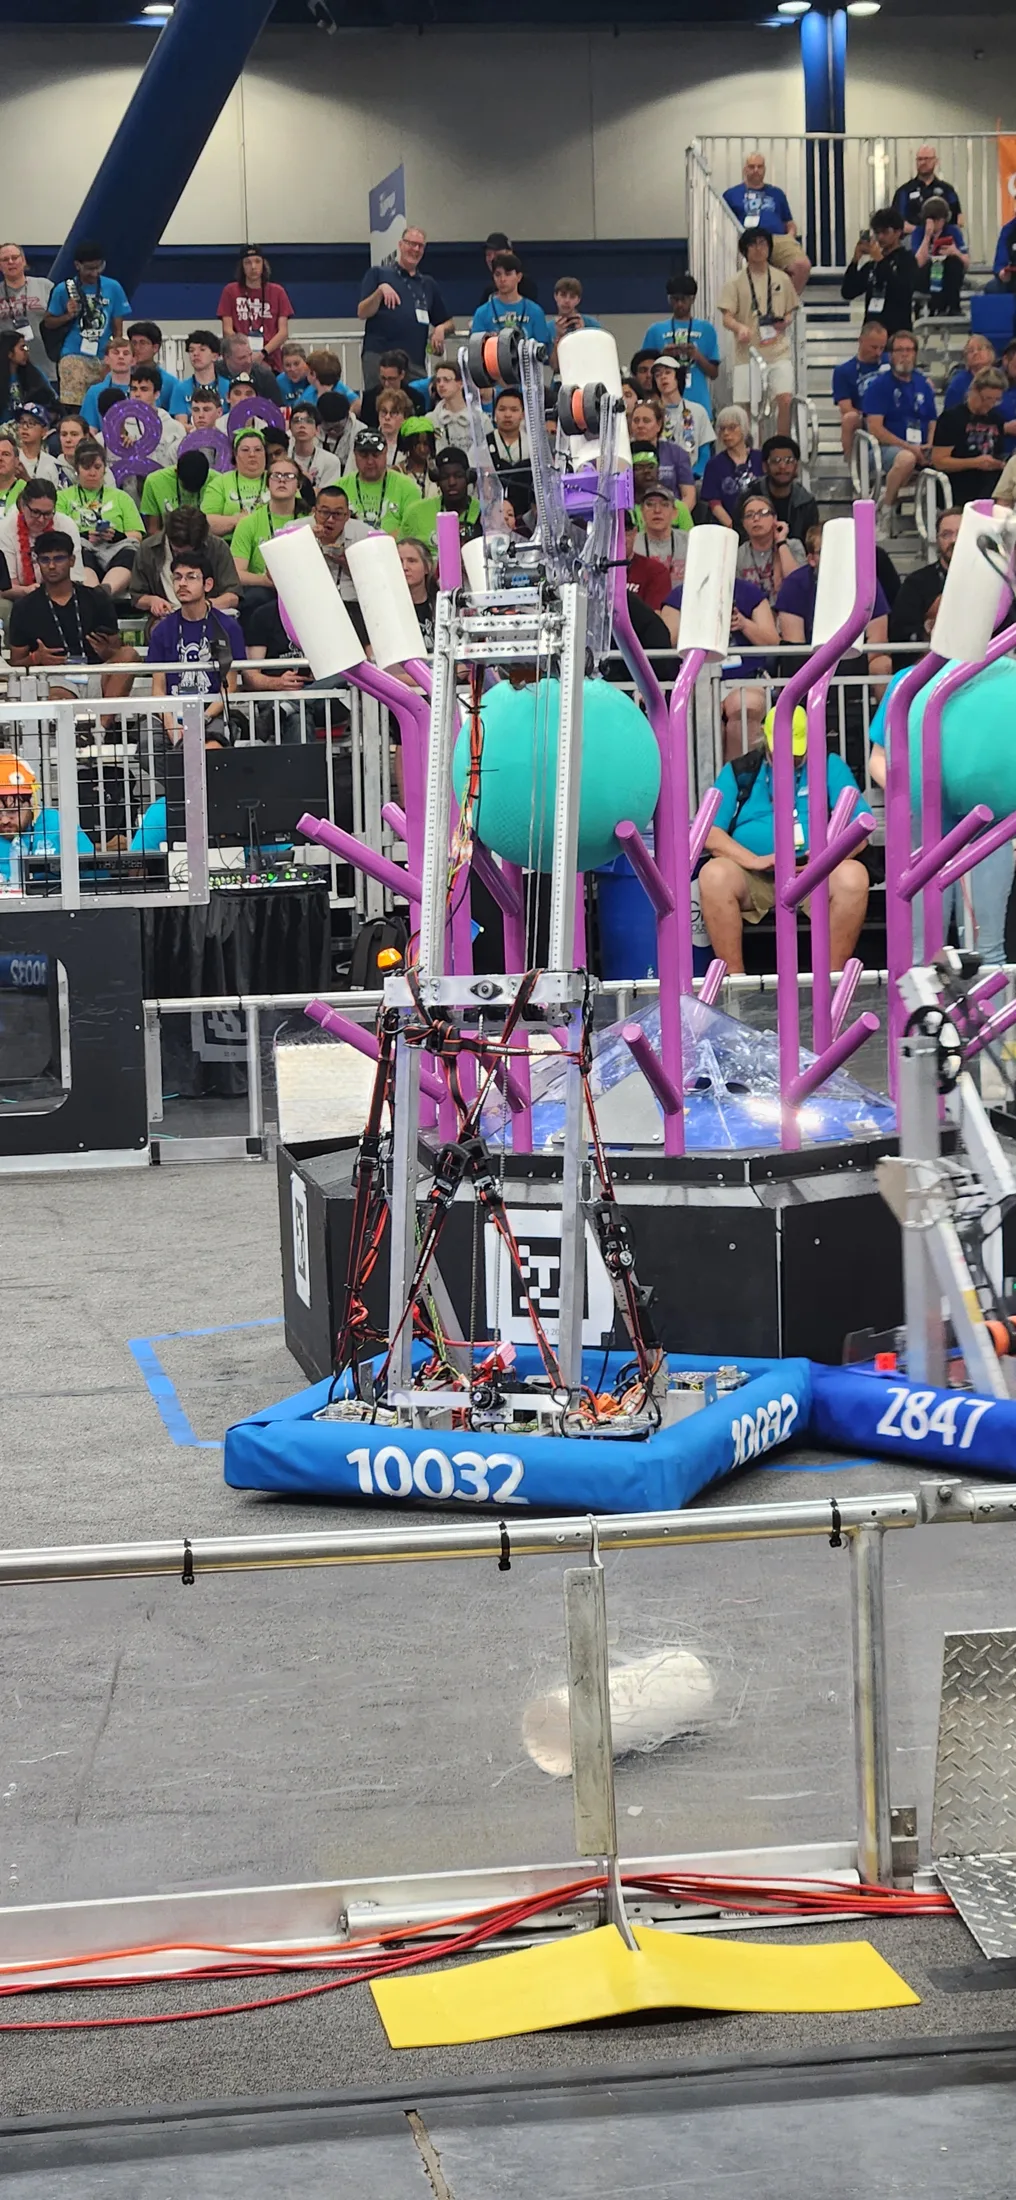
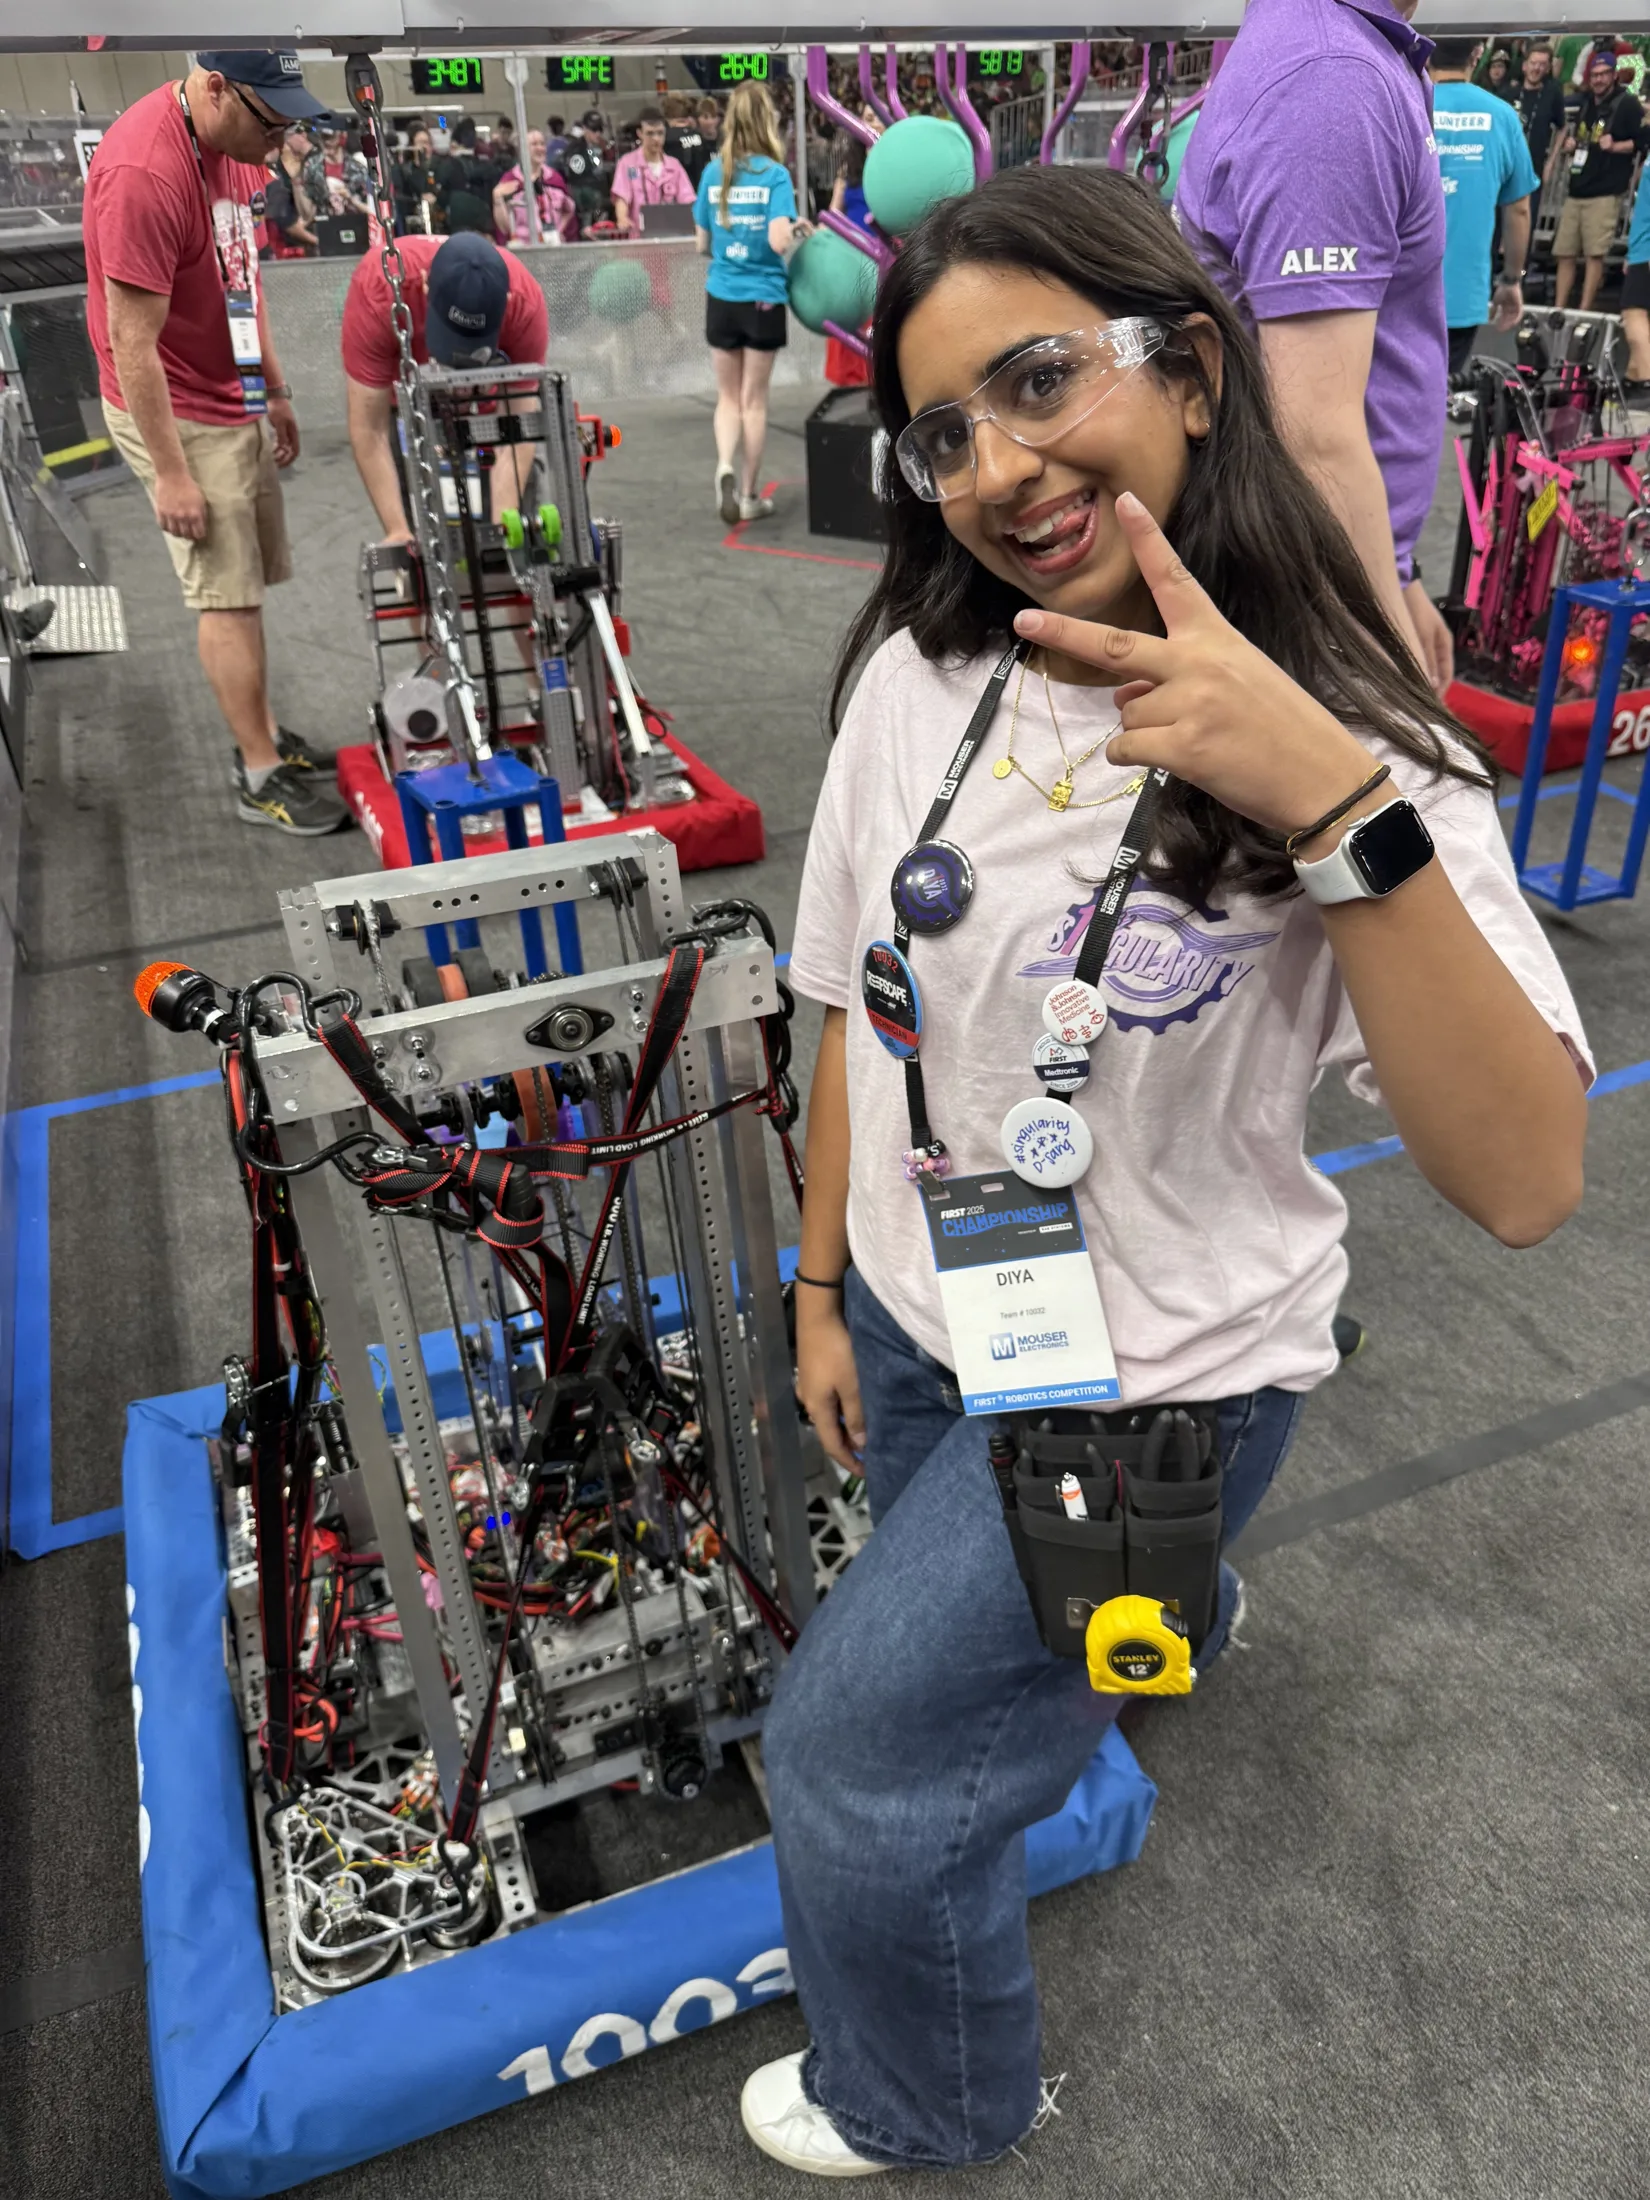
Our rookie-season robot. A vertical elevator carries a pivoting coral end-effector to the reef's scoring levels, a dedicated climber handles the endgame, and a Limelight 3 on a right-side mount feeds the drive team. Aluminum tube and plate frame with a belly pan for the battery, PDH, roboRIO and radio.
01
Elevator
Multi-stage vertical lift. Stage count, gear ratio (7.75:1) and tube wall thickness are configuration options in Onshape, so one model covers every variant we tested.
02
Coral end-effector
Pivoting manipulator on the elevator carriage, with flywheels and coral wheels.
03
Climber
REV MAXPlanetary gearbox through #25 chain on REV hub sprockets, on MAXTube framing.
The 2025 robot